ikd-Tree
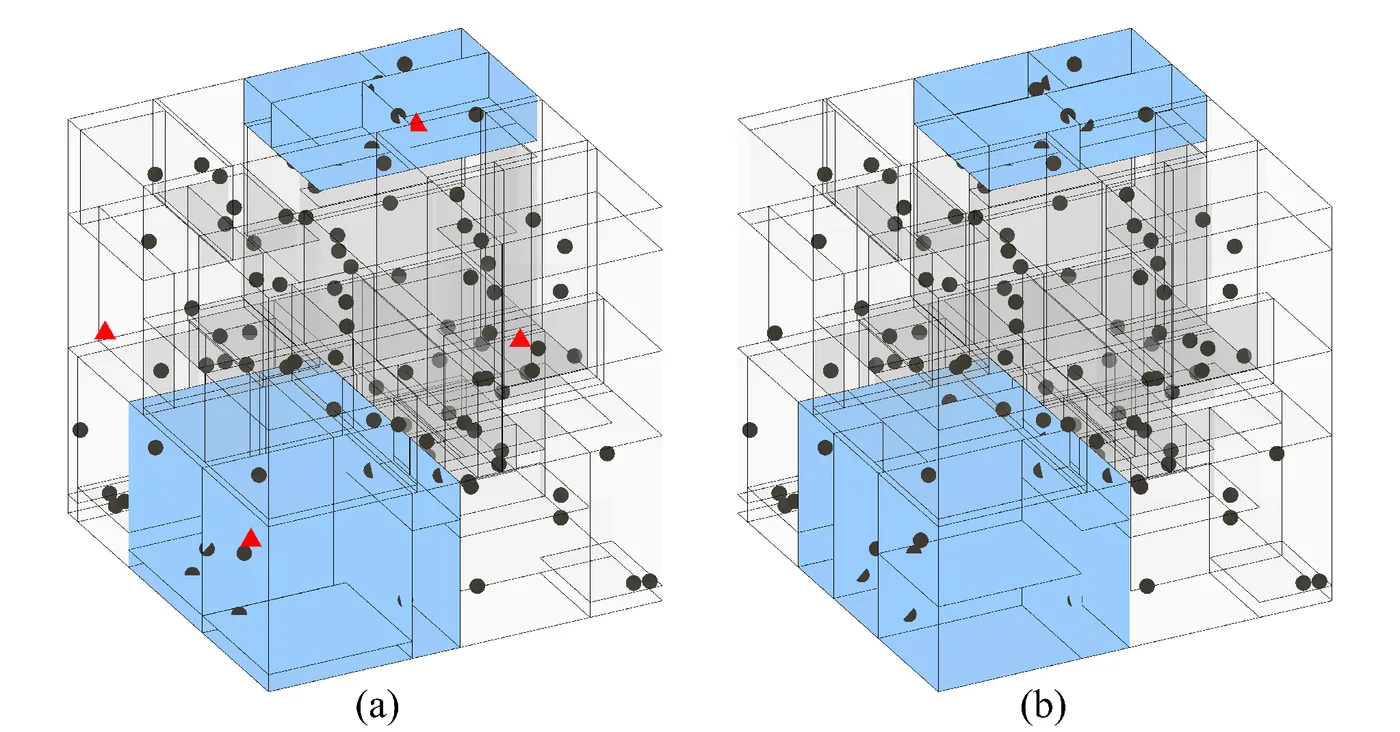
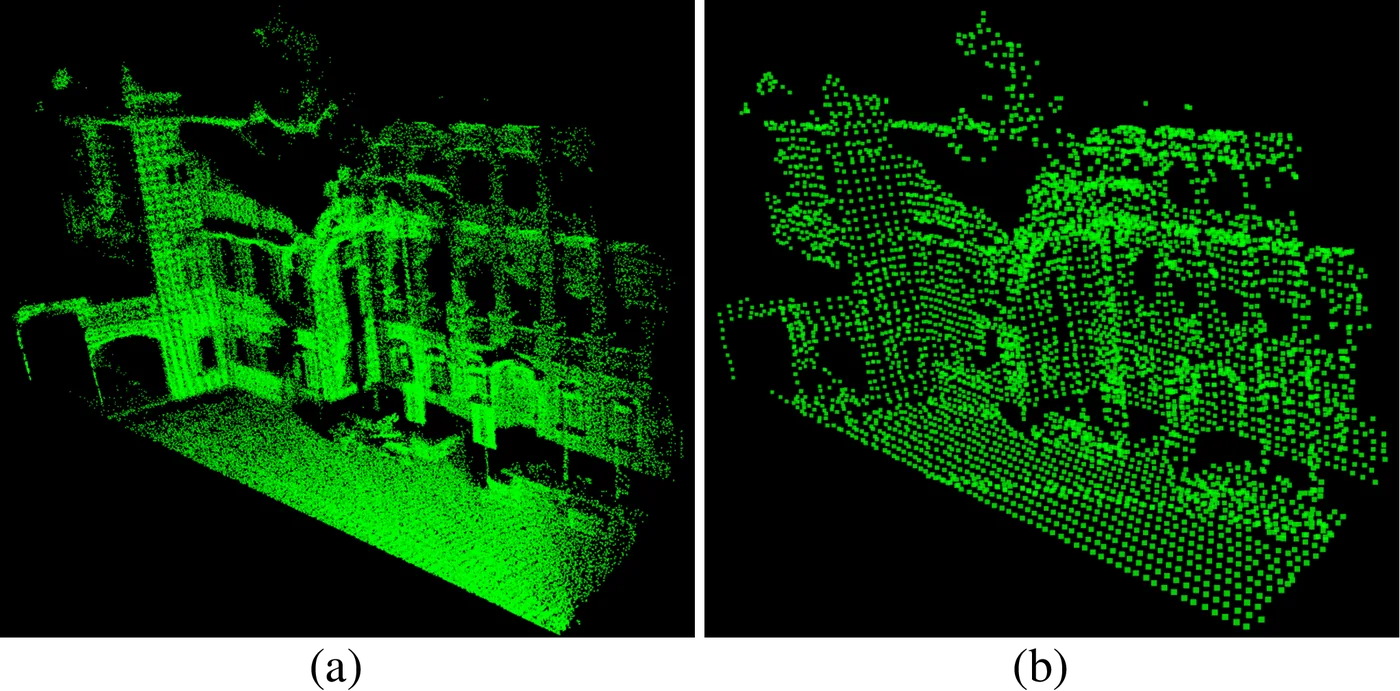
ikd-Tree 讓 k-d 樹只以新進點增量更新,支援單點與方盒範圍的插入、重新插入與刪除(刪除採延遲標記),並在樹上同步降採樣:以邊長 L 的立方格劃分空間,每格只保留最接近格心的點。樹以類似 scapegoat 樹的準則監測平衡並局部重建,大型子樹可交由第二執行緒重建,以維持即時性。
本頁內容
An incremental k-d tree supporting point- and box-wise insert/delete, on-tree voxel downsampling (keeping the point nearest each cell center), and partial rebuilding with optional parallel threads.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | 3D LiDAR、IMU (in the FAST-LIO application test) |
|---|---|
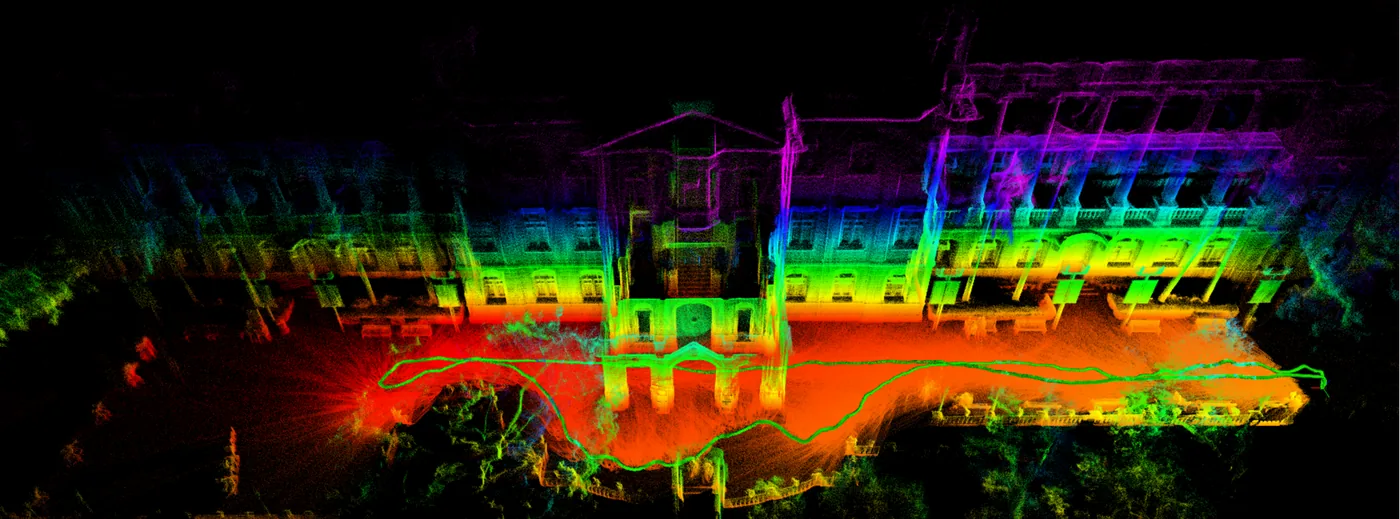
| 原文測試平台 | ["未查證 (outdoor Livox Avia data、Fig. 7 shows the mapping result of the Main Building, University of Hong Kong、onboard computer DJI Manifold 2-C4、carrier not stated)"] |
| 狀態估計 | 不適用 (data structure; tested inside FAST-LIO) |
| 資料關聯 | exact (not approximate) k-nearest-neighbour search that uses per-node range bounds and lazy-label pushdown (Sec. III-E) |
| 時間表示 | 不適用 |
| 去畸變 | 不適用 |
| 迴圈閉合 | 不適用 |
| 全域最佳化 | none |
| 地圖表示 | incremental k-d tree of map points with lazy-delete labels and on-tree voxel downsampling |
| 先驗資訊 | none |
| 可輸出幾何 | downsampled point set stored in the tree |
| 計算需求 | CPU only: randomized tests on a PC with Intel i7-10700 (2.90 GHz, only 2 threads running); FAST-LIO test on a DJI Manifold 2-C4 (quad-core Intel i7-8550U 1.8 GHz, 8 GB RAM); optional second thread rebuilds sub-trees larger than Nmax = 1500 |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
| LiDAR | Livox Avia | 方法輸入 | 未標示 | 70 degree FoV; frame rate 100 Hz | (Cai et al., 2021, Sec. V-B) |
| 運算硬體 | DJI Manifold 2-C4 | 執行運算平台 | 未標示 | 1.8 GHz quad-core Intel i7-8550U CPU, 8 GB RAM | (Cai et al., 2021, Sec. V-B) |
| 運算硬體 | Intel i7-10700 | 執行運算平台 | 未標示 | PC, 2.90 GHz, only 2 threads running | (Cai et al., 2021, Sec. V-A) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
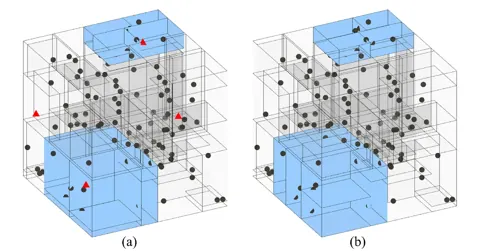
Fig. 1增量式 k-d 樹插入新點與局部重新平衡的立體示意
出處:Cai et al., 2021,Fig. 1。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
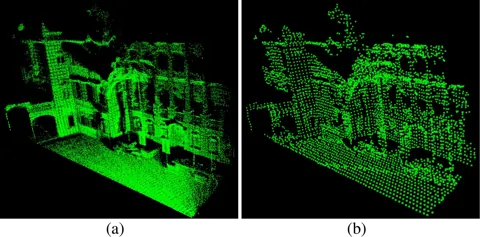
Fig. 2樹上降採樣前後的點雲對照
出處:Cai et al., 2021,Fig. 2。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
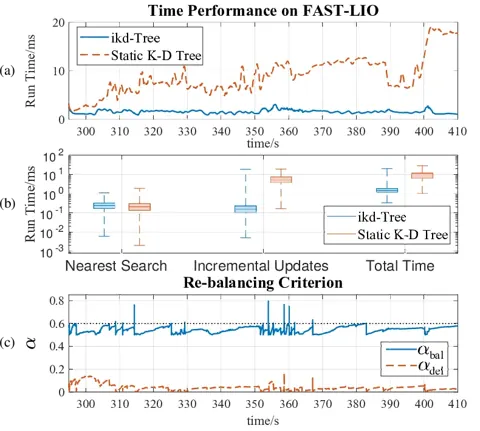
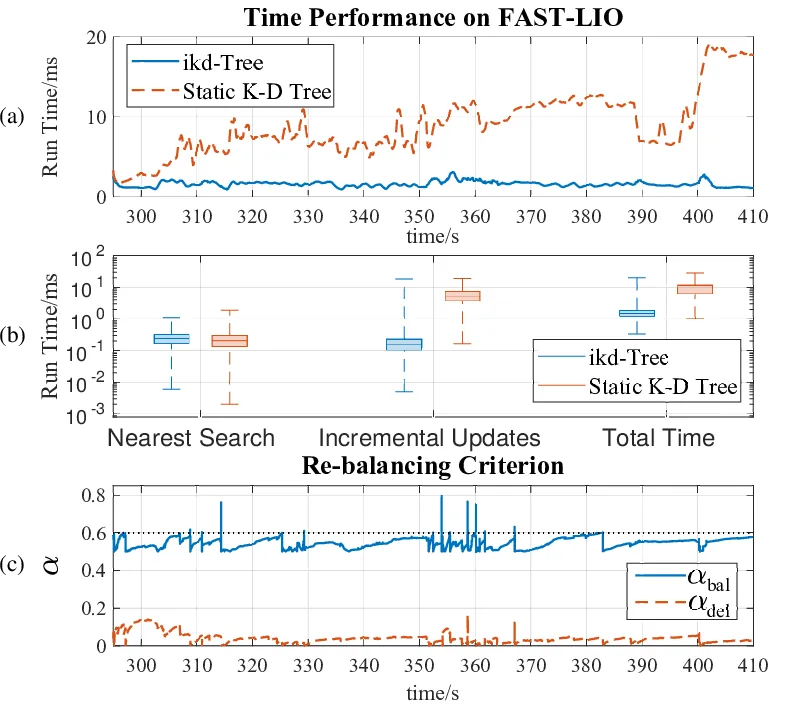
Fig. 6FAST-LIO 中 ikd-Tree 與靜態 k-d 樹融合一筆新掃描的時間、時間分解與平衡指標
出處:Cai et al., 2021,Fig. 6。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
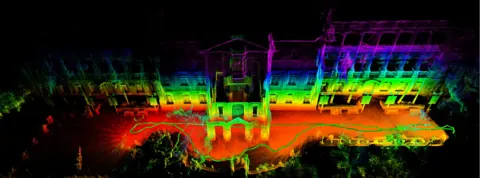
Fig. 7香港大學本部大樓 100 Hz 建圖成果與 LiDAR 軌跡
出處:Cai et al., 2021,Fig. 7。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- ["On randomized data, incremental update time stayed around 1.6 ms while a static kd-tree rebuild grew linearly with points (Sec. V-A, Fig. 4).", "In FAST-LIO the per-scan fusion time stayed nearly constant around 1.6 ms (average of the last 100 scans), enabling mapping up to 100 Hz versus 10 Hz for the original static-tree FAST-LIO
- the static tree exceeded 10 ms per scan from 366 s onward (Sec. V-B, Fig. 6(a)).", "Authors report about two orders of magnitude higher efficiency in their conclusion, while the abstract states ikd-Tree used only 4% of the static k-d tree running time (Sec. VI, Abstract)."]
限制
- ["Insertion of spatially compact data is slower because rebuilds are triggered more often (Sec. V-A, Fig. 5).", "k-nearest search was slightly slower than the PCL static k-d tree in the randomized test (Sec. V-A, Fig. 4(b)).", "Space complexity is O(n) but with a constant a few times larger than a static k-d tree (Sec. IV-B).", "Box-wise operations use boxes aligned with the data coordinate axes (Sec. III-C).", "(inference) The on-tree downsampling keeps one point per cell, so the stored map is a resolution-limited subset of raw measurements rather than all points."]
營建工程相關證據
未在營建場域驗證;唯一實測為香港大學本部大樓的戶外 LiDAR 慣性建圖(Fig. 7)。樹上降採樣在每個邊長 L 的立方格只保留最接近格心的點(FAST-LIO 測試中 L 為 0.2 m,Table II),因此決定 FAST-LIO2 類系統輸出地圖的點密度上限(推論)。
原文驗證環境:模擬、受控實驗
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 2 個比較組,合計 4 筆紀錄。
Cai et al., 2021 · Text Sec. V-B 本方法 3 筆
資料集與序列authors' outdoor recording · Main Building, University of Hong Kong
表格設定(擷取紀錄原文):FAST-LIO on a real outdoor scene with a Livox Avia; time to fuse one new LiDAR scan averaged over the most recent 100 scans; ikd-Tree replaces the static PCL k-d tree for build, update and query; downsampling cube 0.2 m (Cai et al., 2021, Text Sec. V-B)
average running time of fusing one new LiDAR scan,authors' outdoor recording · Main Building, University of Hong Kong
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 未報告(沒有數值,不是 0)
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Cai et al., 2021 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Cai et al., 2021, Text Sec. V-B)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| FAST-LIO with ikd-Tree本方法原文提出硬體:DJI Manifold 2-C4 (Intel i7-8550U, 8 GB RAM) | 1.6 ms有附註註記(擷取紀錄):stated as nearly constant around 1.6 ms | (Cai et al., 2021, Sec. V-B) |
| FAST-LIO with static K-D tree硬體:DJI Manifold 2-C4 (Intel i7-8550U, 8 GB RAM) | 無數值未報告註記(擷取紀錄):increases roughly linearly and exceeds 10 ms from 366 s onward | (Cai et al., 2021, Sec. V-B) |
Cai et al., 2021 · Text Sec. V-A 本方法 1 筆
指標time for incremental updates per test operation, including re-building
資料集與序列randomized synthetic points · incremental test (5,000 to about 200,000 points)
表格設定(擷取紀錄原文):Randomized test: 5,000 initial points in a 10 m cube, 1,000 operations of 200-point insertions and 5-NN queries, periodic box-wise deletes and 2,000-point insertions; tree grows to about 200,000 points; static tree is the PCL k-d tree rebuilt each operation; no downsampling (Cai et al., 2021, Text Sec. V-A)
time for incremental updates per test operation, including re-building,randomized synthetic points · incremental test (5,000 to about 200,000 points)
這張表在此指標與資料序列只列出本方法一筆,沒有可並列的其他方法,因此不畫圖,數值與出處見下表。這是 Cai et al., 2021 在此表設定下報告的數值(author-reported results),不代表方法在其他資料或設定下的表現。
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| ikd-Tree本方法原文提出硬體:PC, Intel i7-10700 2.90 GHz, 2 threads | 1.6 ms有附註註記(擷取紀錄):stated as remaining stably around 1.6 ms | (Cai et al., 2021, Sec. V-A) |
來源
Cai et al., 2021
(2021)ikd-Tree: An Incremental K-D Tree for Robotic ApplicationsarXiv preprint
預印本已讀全文近十年查證後修正
相關版本
- 程式碼釋出:hku-mars/ikd-Tree https://github.com/hku-mars/ikd-Tree
程式碼:https://github.com/hku-mars/ikd-Tree(授權:GPL-2.0 (repository LICENSE))。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。