LiDAR sync by GNSS-clock emulation
本系統以 STM32F4 微控制器模擬 GNSS 時鐘(PPS 與 NMEA GPRMC 訊息)輸入 VLP-16 的硬體同步介面,無需實體 GNSS 接收器,並以中斷為 IMU(MPU-9150)資料打時間戳記。作者以約十分鐘、逾五十萬個 UDP 封包的時間戳週期標準差評估精密度:ROS 抵達時間戳 82.64 µs、LiDAR 內部時鐘 0.31 µs(但無法與其他感測器同步)、本系統 1.35 µs;約 10 µs 的同步準確度則是依感測器文件推估,作者明言實測準確度評估不在本文範圍。
本頁內容
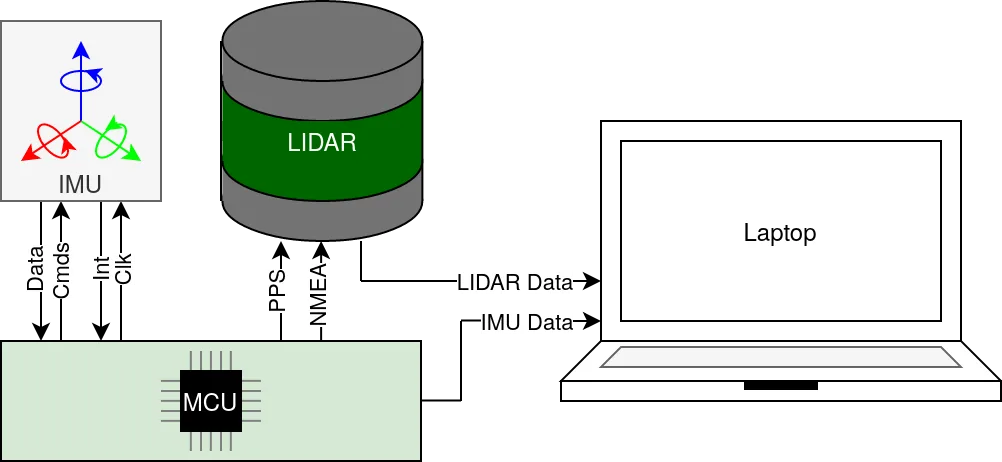
Microcontroller-emulated GNSS clock feeds the LiDAR sync interface and timestamps IMU data, reaching microsecond-level synchronization.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | 3D LiDAR (VLP-16)、IMU (MPU-9150) |
|---|---|
| 原文測試平台 | 4WD wheeled moving platform carrying the IMU, MCU board and laptop (Fig. 1b); the paper does not say whether the Table I recording was made while moving |
| 狀態估計 | 不適用 (hardware timestamping) |
| 資料關聯 | 不適用 |
| 時間表示 | 不適用 |
| 去畸變 | 不適用 |
| 迴圈閉合 | 不適用 |
| 全域最佳化 | none |
| 地圖表示 | 不適用 |
| 先驗資訊 | none |
| 可輸出幾何 | synchronized LiDAR and IMU timestamps |
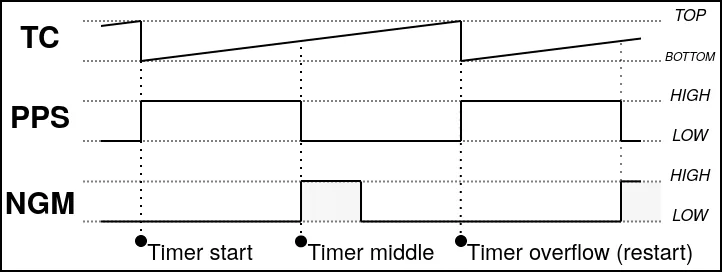
| 計算需求 | STM32F4DISCOVERY MCU platform using one general-purpose timer as real-time clock (resolution 1/76.8 us, about 13 ns), PPS generator and NMEA trigger; firmware built with STM32CubeMX; LiDAR data go directly to a laptop or mini PC, IMU data via the MCU; ROS driver provided |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
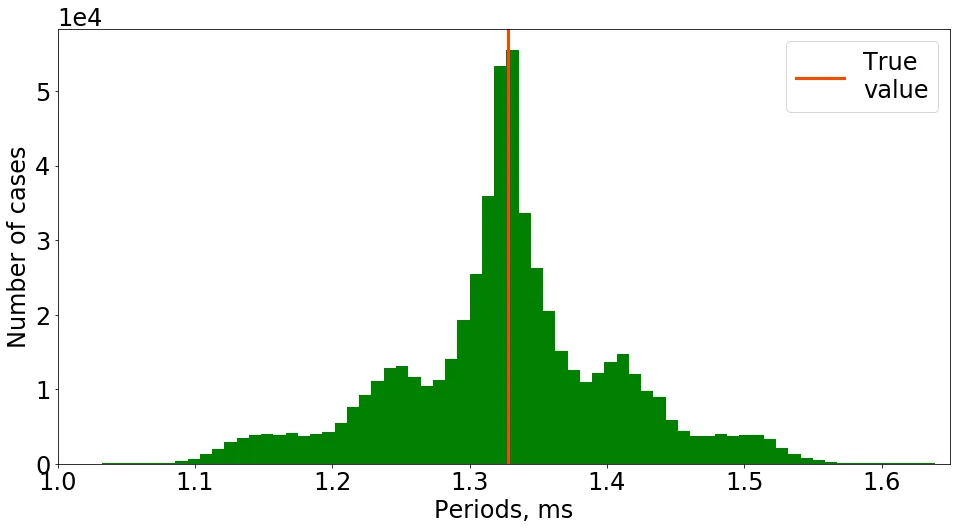
| LiDAR | Velodyne VLP-16 | 方法輸入 | 未標示 | hardware GNSS sync interface (PPS plus NMEA GPRMC); true packet period 1.328 ms and 1 us timestamp resolution per documentation; default 10 rotations per second | (Faizullin et al., 2022, Sec. II, Sec. IV, Fig. 5) |
| 慣性量測單元(IMU) | MPU-9150 | 方法輸入 | 未標示 | 1 kHz sample rate stabilized by an external quartz reference clock from the MCU; data-ready interrupt used for timestamping; interrupt delay documented with 10 us precision | (Faizullin et al., 2022, Sec. II, Sec. IV) |
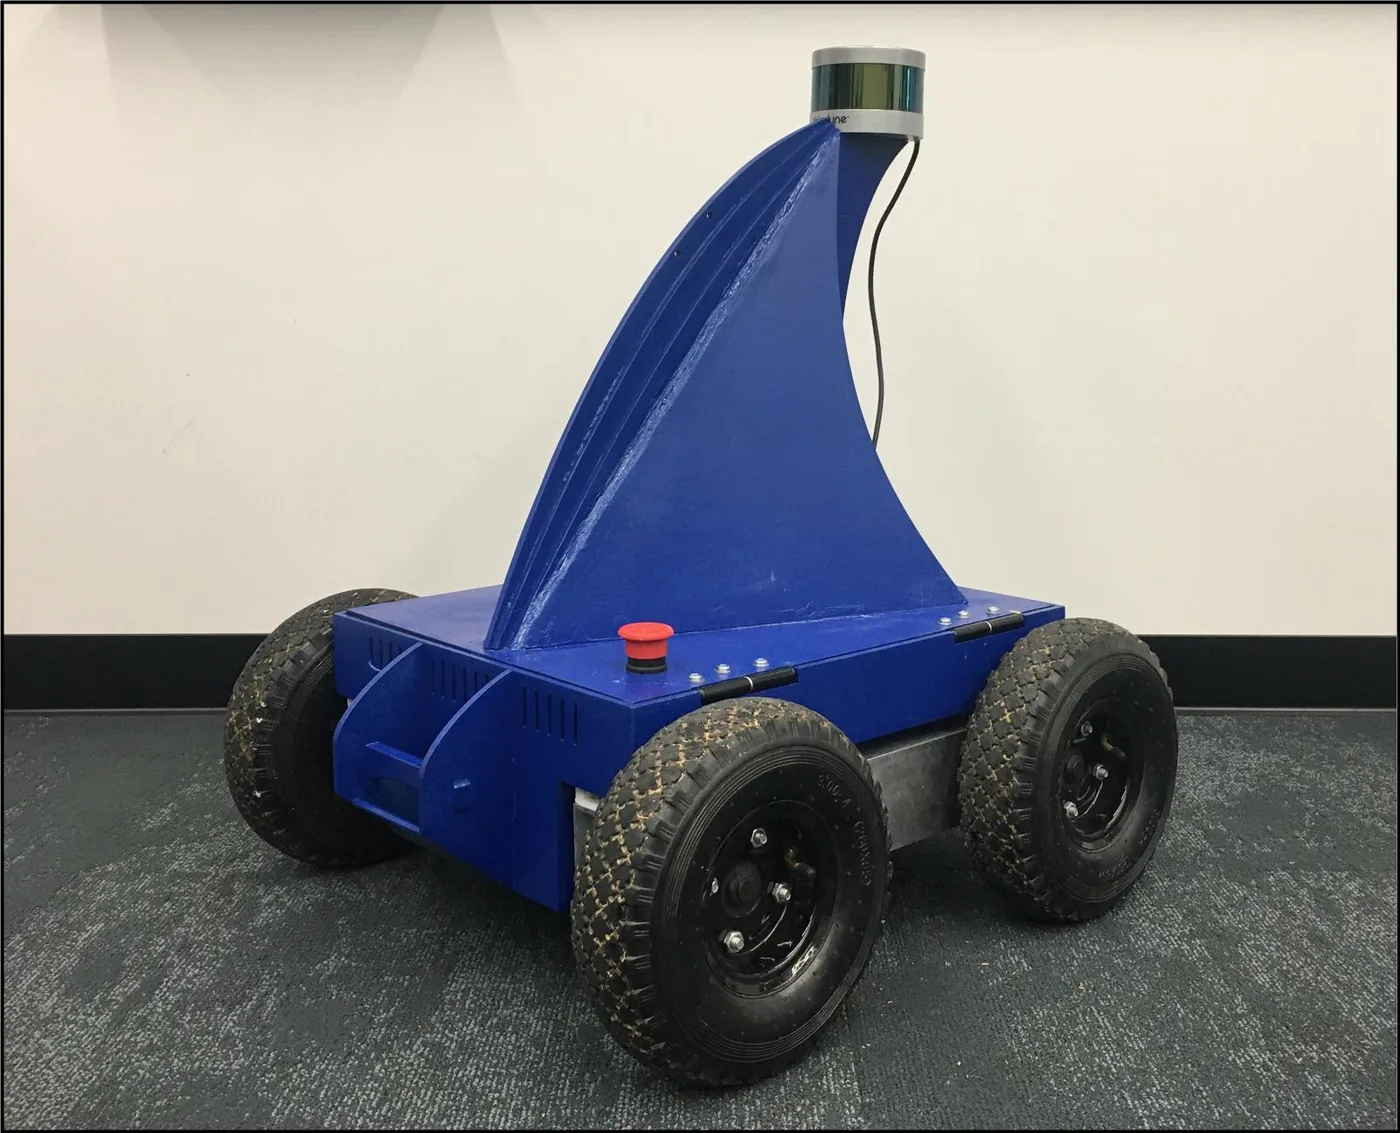
| 載具平台 | 4WD moving platform (model not reported) | 方法輸入 | 未標示 | carries IMU, MCU board, laptop and other equipment inside its body | (Faizullin et al., 2022, Fig. 1(b)) |
| 運算硬體 | laptop or mini PC (model not reported) | 執行運算平台 | 未標示 | receives LiDAR packets and MCU-timestamped IMU data; ROS driver | (Faizullin et al., 2022, Sec. II, Fig. 1) |
| 其他 | STM32F4DISCOVERY | 方法輸入 | 未標示 | MCU platform emulating a GNSS receiver; timer RTC resolution 1/76.8 us (about 13 ns); generates PPS and NMEA GPRMC messages and timestamps IMU samples | (Faizullin et al., 2022, Sec. II, Sec. III) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
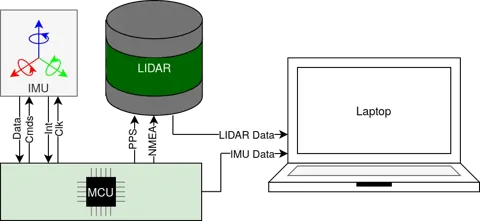
Fig. 1(a)系統方塊圖:MCU 模擬 GNSS 時鐘送 PPS 與 NMEA 至 LiDAR,並以中斷為 IMU 打時間戳
出處:Faizullin et al., 2022,Fig. 1(a)。授權:CC BY-SA 4.0 (arXiv v3); version of record © 2022 IEEE。原始圖檔。修改:轉存為 WebP 格式。
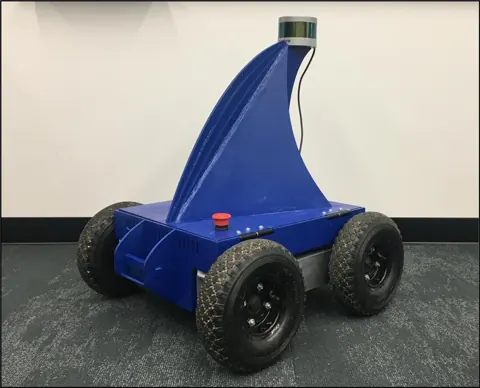
Fig. 1(b)搭載同步系統與 VLP-16 的四輪驅動移動平台外觀
出處:Faizullin et al., 2022,Fig. 1(b)。授權:CC BY-SA 4.0 (arXiv v3); version of record © 2022 IEEE。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
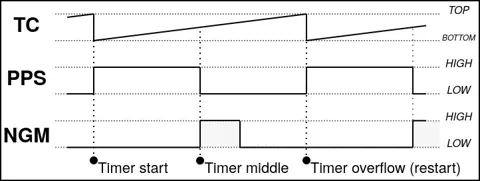
Fig. 4計時器計數值與 PPS 訊號及 NMEA 訊息的時序關係圖
出處:Faizullin et al., 2022,Fig. 4。授權:CC BY-SA 4.0 (arXiv v3); version of record © 2022 IEEE。原始圖檔。修改:轉存為 WebP 格式。
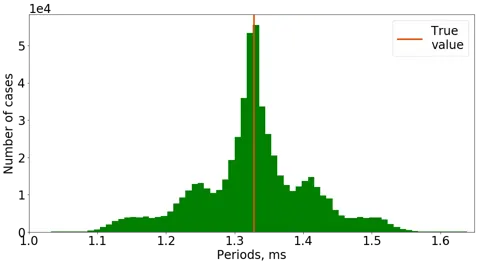
Fig. 5純 ROS 時間戳所得封包週期的分布直方圖與真實週期
出處:Faizullin et al., 2022,Fig. 5。授權:CC BY-SA 4.0 (arXiv v3); version of record © 2022 IEEE。原始圖檔。修改:轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Timestamp-period precision (SD) 1.35 us for the MCU scheme vs 82.64 us for ROS arrival-time stamping (Table I)
- Synchronization accuracy of about 10 us estimated from sensor documentation, not measured (Sec. IV)
限制
- Accuracy statement is for their specific VLP-16 and MPU-9150 setup (Sec. IV)
- Precision (1.35 us SD) is lower than the isolated internal LiDAR clock (0.31 us) because of MCU-to-LiDAR clock drift between PPS pulses (Sec. IV, Table I)
- Synchronization accuracy was not measured empirically; the about 10 us figure is derived from sensor documentation (Sec. IV)
營建工程相關證據
原文未報告(自組量測設備的同步方案,推論可用於工地低成本系統)
原文驗證環境:受控實驗
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 2 個比較組,合計 4 筆紀錄。
Faizullin et al., 2022 · Table I 本方法 3 筆
資料集與序列authors' recording
表格設定(擷取紀錄原文):Packet-to-packet period of VLP-16 timestamps under three timestamping techniques; the text states about 10 min and more than half a million UDP packets only for the ROS timestamps (recording length for the other two techniques not stated); true period 1.328 ms per documentation; STD used as precision (Faizullin et al., 2022, Table I)
STD of timestamp period,authors' recording
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Faizullin et al., 2022 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Faizullin et al., 2022, Table I)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| internal LiDAR clock (authors' driver patch) | 0.31 us有附註註記(擷取紀錄):no time sync with other sensors | (Faizullin et al., 2022, Table I) |
| MCU-based clock (ours)本方法原文提出 | 1.35 us | (Faizullin et al., 2022, Table I) |
Faizullin et al., 2022 · Text Sec. IV 本方法 1 筆
指標time synchronization accuracy
資料集與序列不適用
表格設定(擷取紀錄原文):Synchronization accuracy estimated from LiDAR and IMU documentation and MCU delays; not measured (Faizullin et al., 2022, Text Sec. IV)
time synchronization accuracy,不適用
這張表在此指標與資料序列只列出本方法一筆,沒有可並列的其他方法,因此不畫圖,數值與出處見下表。這是 Faizullin et al., 2022 在此表設定下報告的數值(author-reported results),不代表方法在其他資料或設定下的表現。
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| MCU-based clock (ours)本方法原文提出 | 10 us有附註註記(擷取紀錄):documentation-based estimate, not measured; about 1 us order stated for two or more LiDARs of the same type | (Faizullin et al., 2022, Sec. IV) |
來源
Faizullin et al., 2022
(2022)Open-Source LiDAR Time Synchronization System by Mimicking GNSS-clock2022 IEEE International Symposium on Precision Clock Synchronization for Measurement, Control, and Communication (ISPCS), pp. 1-5
DOI 10.1109/ispcs55791.2022.9918446arXiv 2107.02625程式碼
同儕審查已出版已讀全文近十年查證後修正
相關版本
- 預印本:Open-Source LiDAR Time Synchronization System by Mimicking GPS-clock (earlier arXiv title) https://arxiv.org/abs/2107.02625
程式碼:https://github.com/MobileRoboticsSkoltech/lidar-sync-mimics-gps(授權:none found (no LICENSE file and no license statement in README; checked 2026-09-25))。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。