Pronto
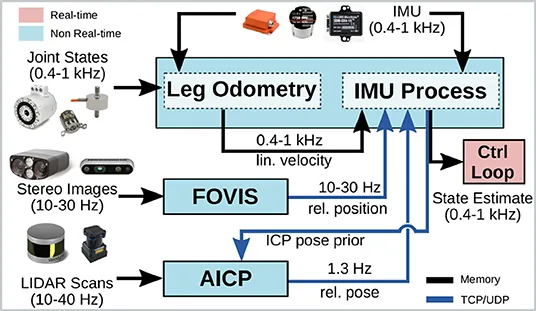
Pronto 是為腿式機器人設計的模組化擴展卡爾曼濾波器:以 IMU 作為高頻過程模型,先融合腿部運動學與接觸偵測得到的速度,再把延遲且低頻的視覺里程計與 LiDAR 點雲配準結果,以鬆耦合的位姿修正方式插入約 10 秒的量測歷史中重新傳播。這樣可在控制迴路中提供 250 至 1000 Hz 的低延遲狀態估測,同時利用外感測器抑制長時間漂移。
本頁內容
Modular EKF for legged robots that runs an IMU process model with leg-odometry velocity updates at control rate and inserts delayed, low-rate visual odometry and ICP-based LiDAR corrections into a stored measurement history, giving low-latency, low-drift estimates for closed-loop locomotion.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | IMU (KVH 1750, KVH 1775, 3DM-GX4-25 or Xsens MTi-100 depending on robot)、joint encoders and force or torque sensing for leg odometry、stereo camera (Carnegie Robotics Multisense SL) or RGB-D camera (Intel RealSense D435) for FOVIS visual odometry、LiDAR (Hokuyo UTM-30LX-EW spinning in the Multisense SL, or Velodyne VLP-16 on ANYmal) for AICP registration |
|---|---|
| 原文測試平台 | Atlas humanoid、Valkyrie humanoid、HyQ quadruped、ANYmal quadruped |
| 狀態估計 | modular extended Kalman filter with an IMU process model on the real-time control computer; leg-odometry velocity updates; zero-velocity gyro bias update when stationary at least 400 ms; loosely coupled pose or position corrections from FOVIS visual odometry and from AICP LiDAR registration applied through a measurement history of typically 10 s to handle their latency (Secs. 4-5) |
| 資料關聯 | leg odometry from kinematics with contact detection (Schmitt trigger on humanoids, probabilistic ground-reaction-force contact on quadrupeds); FOVIS feature-based stereo or RGB-D visual odometry; AICP auto-tuned ICP with planar pre-filtering and overlap-based outlier rejection against a reference cloud (Sec. 4) |
| 時間表示 | discrete EKF at the IMU rate (250 to 1000 Hz) with delayed asynchronous exteroceptive updates at 1 to 15 Hz inserted into the stored history and re-propagated (Sec. 5.1; Fig. 6) |
| 去畸變 | not described in the paper; AICP registers accumulated point clouds |
| 迴圈閉合 | no |
| 全域最佳化 | none; the filter marginalizes previous states (Sec. 9) |
| 地圖表示 | AICP reference point cloud updated after a travelled distance; no global map is maintained by the estimator |
| 先驗資訊 | robot kinematic model; fixed measurement covariances per module; for HyQ outdoor ground truth an ICP prior map was used for evaluation only |
| 可輸出幾何 | base pose and velocity at control rate for closed-loop locomotion |
| 計算需求 | consumer-grade processors (e.g., laptop-class Intel i7), no GPU; proprioceptive thread on the control computer, VO and LiDAR on a perception computer (Sec. 5) |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
| LiDAR | UTM-30LX-EW (spinning, in Multisense SL)歸入:Hokuyo UTM-30LX | 方法輸入 | Atlas, Valkyrie, HyQ | 40 Hz; full-rotation FoV 220 x 180 deg (Atlas entry); produces sparse clouds that AICP accumulates | (Camurri et al., 2020, Table 1) |
| LiDAR | VLP-16歸入:Velodyne VLP-16 | 方法輸入 | ANYmal | mounted on top of ANYmal for localization and global mapping; used by AICP | (Camurri et al., 2020, Sec. 6.4) |
| 慣性量測單元(IMU) | KVH 1750 | 方法輸入 | Atlas (DRC Finals) | 333 Hz; initial bias 0.5 deg/h and 0.5 mg; bias stability 0.05 deg/h and 0.05 mg | (Camurri et al., 2020, Table 1) |
| 慣性量測單元(IMU) | 3DM-GX4-25 | 方法輸入 | Valkyrie | 500 Hz | (Camurri et al., 2020, Table 1) |
| 慣性量測單元(IMU) | KVH 1775 | 方法輸入 | HyQ | 1000 Hz; initial bias 0.5 deg/h and 0.5 mg; bias stability 0.05 deg/h and 0.05 mg | (Camurri et al., 2020, Table 1) |
| 慣性量測單元(IMU) | MTi-100歸入:Xsens MTi-100 | 方法輸入 | ANYmal | 400 Hz; initial bias 0.2 deg/s and 5 mg; bias stability 10 deg/h and 15 mg | (Camurri et al., 2020, Table 1) |
| 雙目相機 | Multisense SL | 方法輸入 | Atlas, Valkyrie, HyQ | tri-modal ruggedized sensor; stereo 10 Hz, 1024 x 1024 px, 80 x 80 deg FoV (CMV4000 imager) on Atlas; used on Atlas, Valkyrie and HyQ | (Camurri et al., 2020, Table 1; Sec. 6) |
| RGB-D 相機 | RealSense D435歸入:Intel RealSense D435 | 方法輸入 | ANYmal | 30 Hz, 848 x 480 for VO; a second downward-facing D435 also mounted | (Camurri et al., 2020, Table 1; Sec. 7.5) |
| 輪式或腿式里程計 | AEDA3300-BE1 | 方法輸入 | HyQ | joint encoders, 1,000 Hz, resolution <0.0045 deg; leg odometry input | (Camurri et al., 2020, Table 1) |
| 輪式或腿式里程計 | ANYdrive | 方法輸入 | ANYmal | joint encoders (resolution <0.025 deg) and torque at 400 Hz; leg odometry input | (Camurri et al., 2020, Table 1) |
| 全測站 | TS16 | 參考或真值量測 | ANYmal (Fire Service College) | laser tracking system following a reflective prism with millimetre accuracy; ANYmal experiment | (Camurri et al., 2020, Sec. 7.1.1) |
| 其他 | Omega85 | 方法輸入 | Valkyrie | foot force and torque sensing for contact detection | (Camurri et al., 2020, Table 1) |
| 其他 | Vicon | 參考或真值量測 | Valkyrie, HyQ | 100 Hz, millimetre-accurate; Valkyrie and HyQ indoor experiments | (Camurri et al., 2020, Sec. 7.1.1) |
| 其他 | Burster 8417 | 方法輸入 | HyQ | force sensing, 1,000 Hz, resolution <25 N | (Camurri et al., 2020, Table 1) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
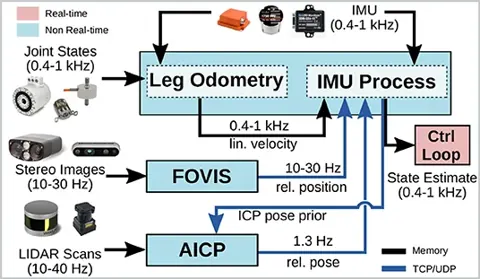
Figure 5系統方塊圖:IMU 過程模型與腿部里程計在控制電腦即時執行,視覺里程計與 LiDAR 配準在感知電腦執行後回饋修正
出處:Camurri et al., 2020,Figure 5。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
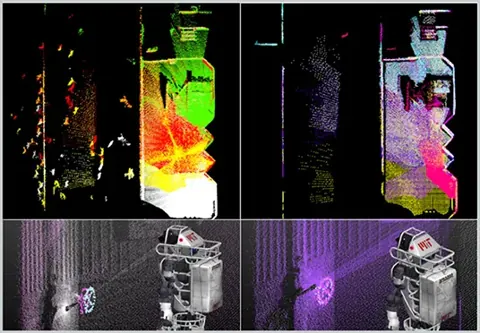
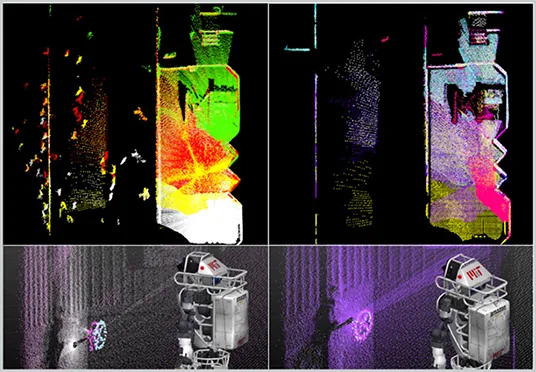
Figure 7Atlas 在 DRC 決賽資料上的 AICP 表現:上方為 206 片點雲對齊結果的上視圖,左為含人群的原始點雲,右為濾除後點雲;下方比較未套用修正時閥門在各片點雲中位置不一致,以及定位成功後估測一致的結果
出處:Camurri et al., 2020,Figure 7。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
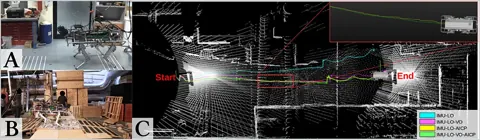
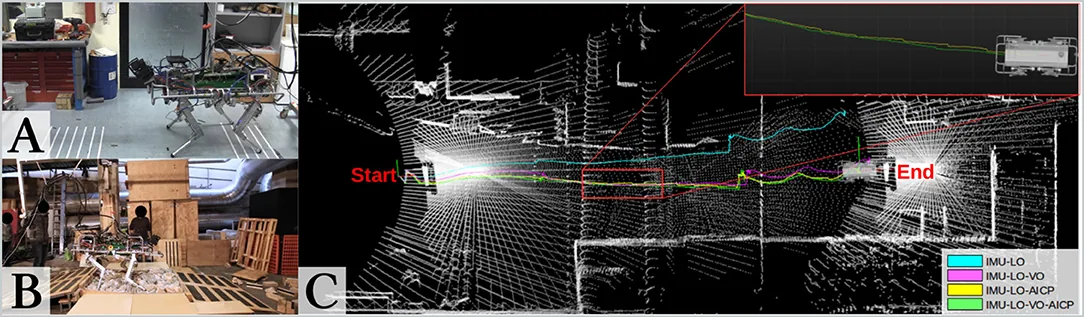
Figure 9HyQ 室內重複性測試、室外昏暗工業區探索測試,以及不同感測組合估測軌跡的比較
出處:Camurri et al., 2020,Figure 9。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
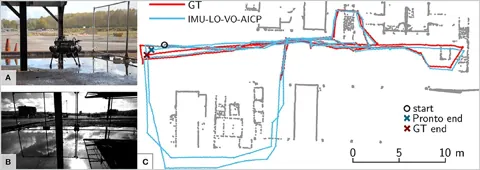
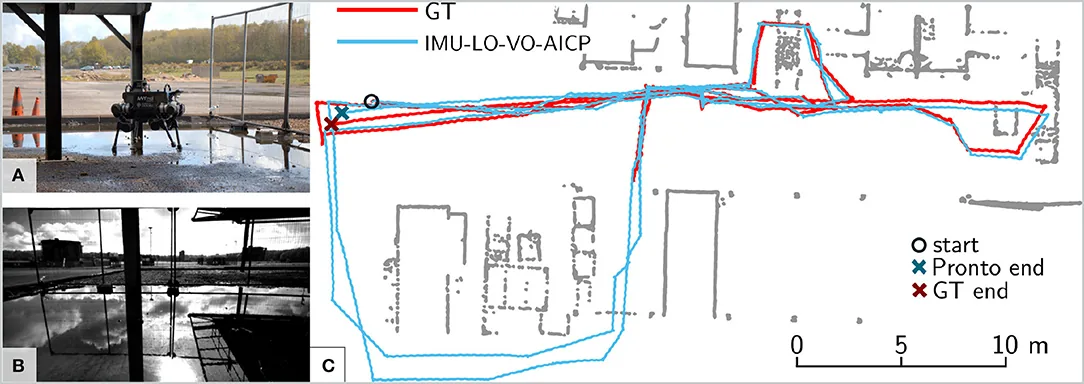
Figure 12ANYmal 在消防訓練場的實驗:場景照片、機上相機畫面(水面反光),以及估測軌跡與真值比較
出處:Camurri et al., 2020,Figure 12。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Validated on four legged robots over more than 2 h and 1.37 km, including closed-loop control during dynamic gaits (Sec. 7; Table 2)
- RPE over 10 m of 0.016 to 0.033 m in the smaller humanoid and HyQ experiments (Table 2)
- On Valkyrie the translation error averaged 1.6 cm and never exceeded 7.5 cm, while the estimator without LiDAR drifted without bound (Sec. 7.3)
- On ANYmal in an industrial fire-training site, fusing VO and AICP reduced RPE by 60 % compared with IMU and leg odometry only; the pose was within 30 cm of ground truth after 240 m (Sec. 7.5)
- Runs on laptop-class CPUs without GPU and is released as open-source ROS packages (Sec. 5)
限制
- No triaging when exteroceptive sources disagree; measurement confidence is a fixed covariance (Sec. 8)
- Loosely coupled design; the authors name tightly coupled joint optimization as future work (Sec. 8)
- No loop closure or global map; ground truth was not available for all experiments (Table 2)
- The Atlas and HyQ outdoor accuracy values are bounds from indirect evaluation (Table 2 footnotes)
營建工程相關證據
腿式機器人(如 ANYmal、Spot)已用於工地巡檢與掃描,本文提供其底層狀態估測的完整設計與長時間實測。ANYmal 實驗在消防訓練場的工業設施內進行,有水面反光、低光照與崎嶇地形,並以 Leica TS16 全測站作為真值,與施工現場的條件部分相近(推論)。但本文只評估位姿,不產生或評估點雲地圖。
原文驗證環境:受控實驗、獨立參考量測、跨場域
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 2 個比較組,合計 14 筆紀錄。
Camurri et al., 2020 · Table 2 本方法 8 筆
表格設定(擷取紀錄原文):Summary of experiments; RPE = translational part of relative pose error evaluated over 10 m distance; OL = online, CL = used in the control loop; GT = ground truth available (Vicon for Valkyrie and HyQ indoor, Leica TS16 for ANYmal) (Camurri et al., 2020, Table 2)
RPE [m], over 10 m,Pronto experiments (authors) · Exp. 7 (ANYmal)
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Camurri et al., 2020 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Camurri et al., 2020, Table 2)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| Pronto (IMU+LO+VO+AICP, offline)本方法原文提出 | 0.34 m | (Camurri et al., 2020, Table 2) |
| Pronto (IMU+LO only (without VO and AICP), offline)本方法原文提出 | 0.83 m | (Camurri et al., 2020, Table 2) |
Camurri et al., 2020 · Sec. 7 text 本方法 6 筆
資料集與序列Pronto experiments (authors) · Exp. 6c-6e (HyQ)
表格設定(擷取紀錄原文):Values stated in the text of Section 7 (Camurri et al., 2020, Sec. 7 text)
average 3D median translation error,Pronto experiments (authors) · Exp. 6c-6e (HyQ)
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Camurri et al., 2020 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Camurri et al., 2020, Sec. 7 text)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| Pronto (IMU+LO+AICP)本方法原文提出 | 0.049 m有附註註記(擷取紀錄):approximate as printed ('~4.9 cm') | (Camurri et al., 2020, Sec. 7.4; Fig. 11) |
| Pronto (IMU+LO+AICP+VO)本方法原文提出 | 0.032 m | (Camurri et al., 2020, Sec. 7.4; Fig. 11) |
來源
Camurri et al., 2020
(2020)Pronto: A Multi-Sensor State Estimator for Legged Robots in Real-World ScenariosFrontiers in Robotics and AI, 7, article 68
DOI 10.3389/frobt.2020.00068程式碼
同儕審查已出版已讀全文近十年查證後修正
相關版本
- 程式碼釋出:ori-drs/pronto (core EKF and leg odometry), with fovis_ros and aicp_mapping modules https://github.com/ori-drs/pronto
程式碼:https://github.com/ori-drs/pronto(授權:LGPL-2.1 (GitHub license metadata for ori-drs/pronto))。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。