2DGS
2DGS 將三維體積壓縮為一組有方向的二維平面高斯圓盤,使基元在多視角下具一致的幾何,並加入深度失真與法向一致性正則化。網格以渲染深度圖經 TSDF 融合取得。作者在 DTU 以 Chamfer 距離、在 Tanks and Temples 以 F1 評估幾何,指出幾何與影像品質之間存在取捨。
本頁內容
Replaces 3D Gaussians with planar 2D Gaussian disks plus depth-distortion and normal regularization to obtain view-consistent geometry, meshed by TSDF fusion of rendered depth.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | monocular camera (multi-view images) |
|---|---|
| 原文測試平台 | 未記錄 |
| 狀態估計 | 不適用 (per-scene optimization; poses from COLMAP) |
| 資料關聯 | direct photometric loss with depth-distortion and normal-consistency regularization |
| 時間表示 | 不適用 |
| 去畸變 | 不適用 |
| 迴圈閉合 | none |
| 全域最佳化 | none |
| 地圖表示 | 2D oriented planar Gaussian disks (surfels) with perspective-correct ray-splat intersection |
| 先驗資訊 | COLMAP cameras and sparse points |
| 可輸出幾何 | mesh by TSDF fusion (Open3D, voxel size 0.004, truncation 0.02) of rendered median depth maps of the training views; median depth outperforms expected depth and screened Poisson reconstruction in the DTU ablation |
| 計算需求 | Custom CUDA kernels built on the 3DGS framework; all experiments on a single RTX 3090 GPU (written 'GTX RTX3090'); DTU training 5.5 min (15k iterations) or 10.9 min (30k), Tanks and Temples 15.5 min, DTU model 52 MB |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
| 運算硬體 | GTX RTX3090 (as written)歸入:GTX RTX3090 | 執行運算平台 | 未標示 | single GPU for all experiments | (Huang et al., 2024a, Sec. 6.1) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
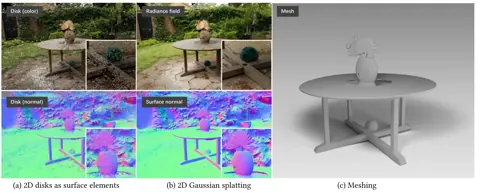
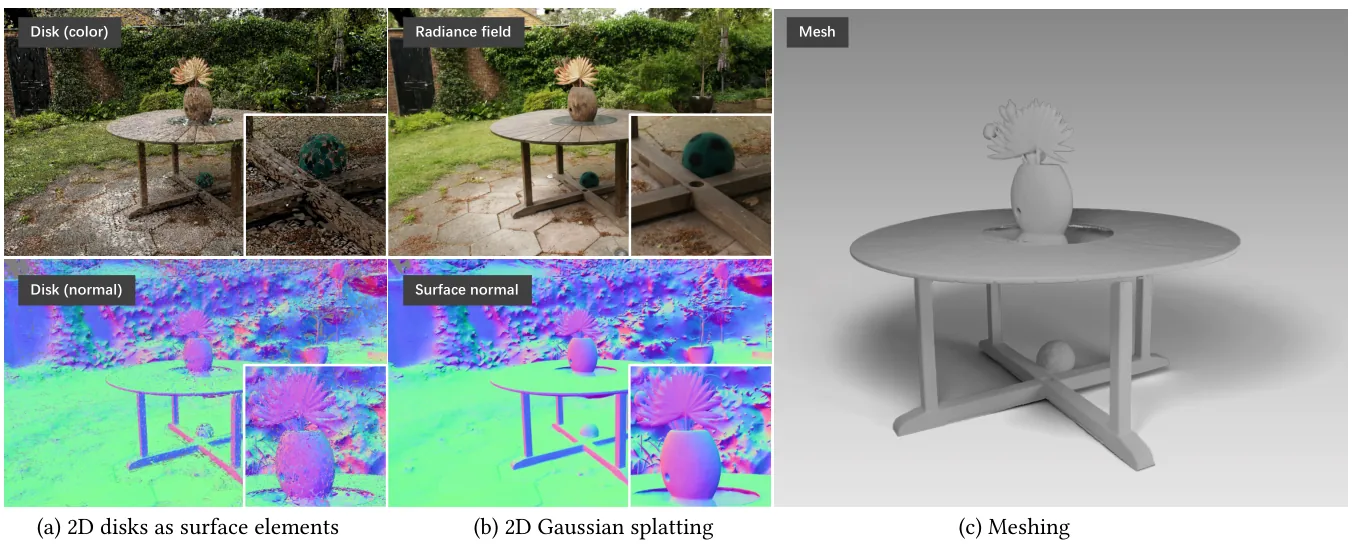
Fig. 12DGS 以二維定向圓盤重建真實場景,並輸出一致的法向、深度與無雜訊網格
出處:Huang et al., 2024a,Fig. 1。授權:CC BY 4.0 (arXiv v3; ACM version also CC BY 4.0)。原始圖檔。修改:轉存為 WebP 格式。
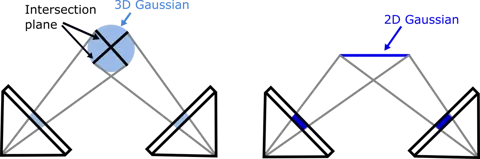
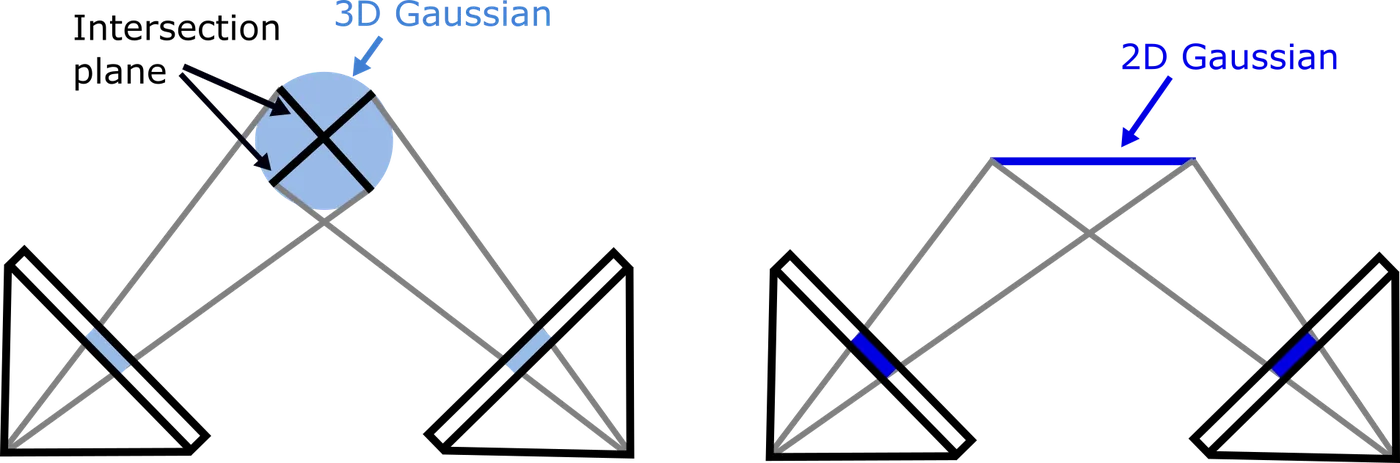
Fig. 23DGS 與 2DGS 的比較:3DGS 在不同視角使用不同交會平面,2DGS 具多視角一致性
出處:Huang et al., 2024a,Fig. 2。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
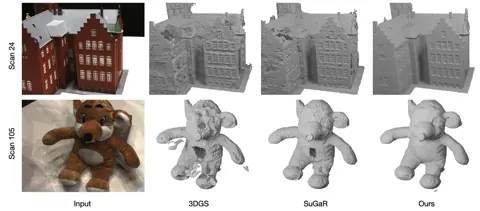
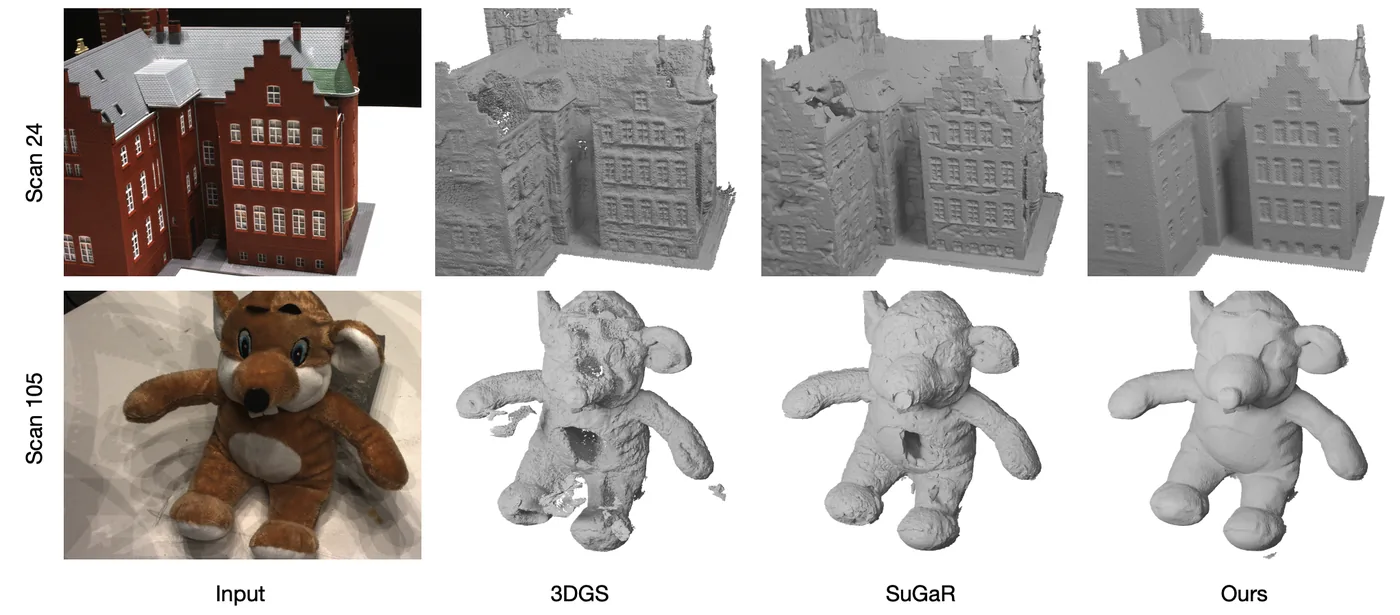
Fig. 5DTU 資料集的定性比較,2DGS 表面細緻且雜訊少
出處:Huang et al., 2024a,Fig. 5。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
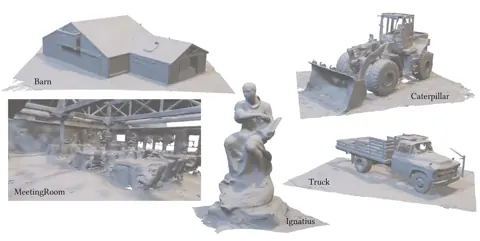
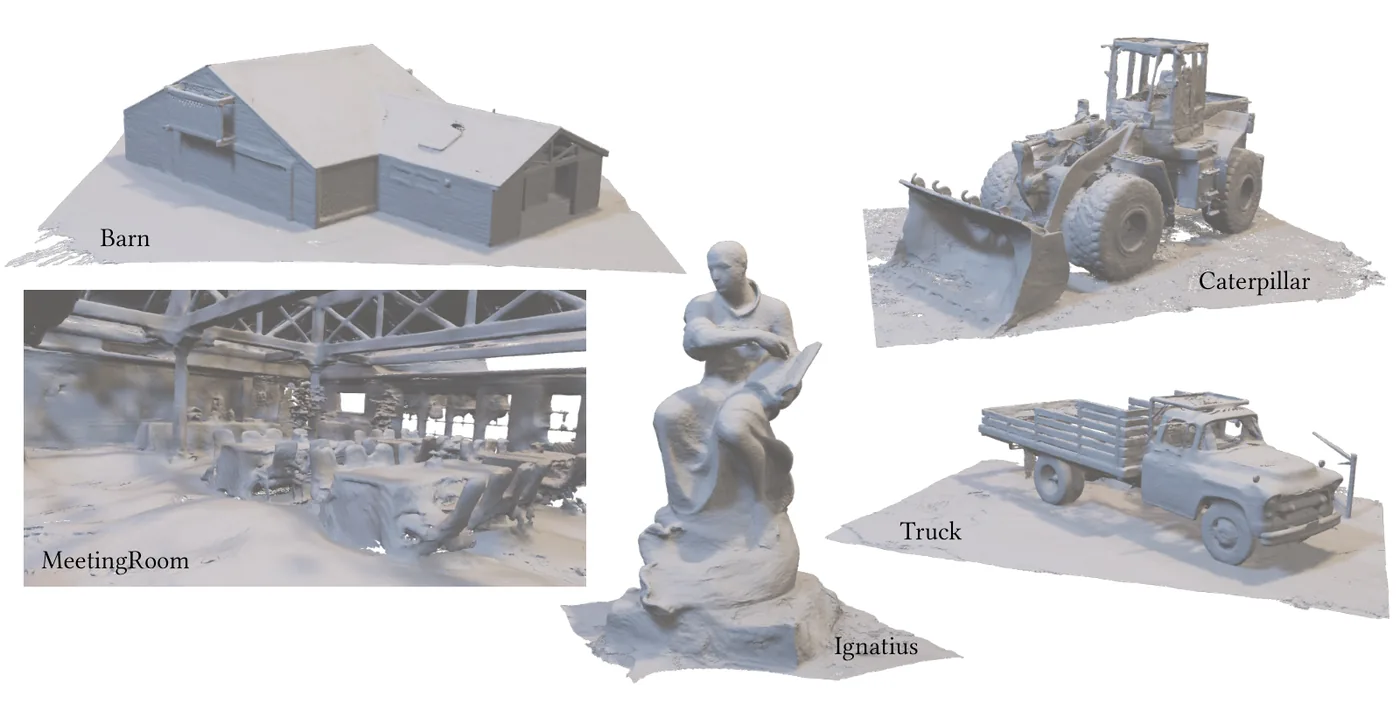
Fig. 10Tanks and Temples 資料集的表面重建定性結果
出處:Huang et al., 2024a,Fig. 10。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Lowest mean DTU Chamfer distance among compared methods: 0.80 (30k iterations) vs NeuS 0.84, VolSDF 0.86, SuGaR 1.33 and 3DGS 1.96 (Table 1)
- About 100 times faster than SDF baselines on DTU (10.9 min vs more than 12 h) (Table 1)
- Tanks and Temples mean F1 0.32 vs 0.09 for 3DGS and 0.19 for SuGaR (Table 2)
- Competitive novel-view synthesis on Mip-NeRF 360 (outdoor PSNR 24.34 vs 24.64 for 3DGS) (Table 4)
限制
- Assumes fully opaque surfaces; semi-transparent surfaces such as glass are problematic (Limitations, Fig. 12)
- Densification favours texture-rich over geometry-rich areas (Limitations)
- Regularization trades image quality against geometry and may over-smooth (Limitations)
- Tends to create holes in areas with high light intensity (Fig. 12)
- Tanks and Temples mean F1 (0.32) stays below implicit SDF methods Neuralangelo (0.50) and NeuS (0.38) (Table 2)
營建工程相關證據
原論文未涉及營建;2DGS 已被用於隧道與建築外殼的營建研究,見(Qian et al., 2026)、(Chowdhury et al., 2026)(依其摘要)。
原文驗證環境:公開基準
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 4 個比較組,合計 47 筆紀錄。
Huang et al., 2024a · Table 1 本方法 34 筆
表格設定(擷取紀錄原文):Chamfer distance per DTU scan (15 scans) and mean; meshes of 3DGS and 2DGS by TSDF fusion of rendered depth; unit not stated in the paper; images downsampled to 800 x 600; COLMAP sparse points for initialization (Huang et al., 2024a, Table 1)
Chamfer distance (CD),DTU · scan 24
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Huang et al., 2024a 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Huang et al., 2024a, Table 1)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| NeRF (Mildenhall et al., 2021) | 1.9 | (Huang et al., 2024a, Table 1) |
| VolSDF (Yariv et al., 2021) | 1.14 | (Huang et al., 2024a, Table 1) |
| NeuS (Wang et al., 2021) | 1 | (Huang et al., 2024a, Table 1) |
| 3DGS (Kerbl et al., 2023) | 2.14 | (Huang et al., 2024a, Table 1) |
| SuGaR (Guédon and Lepetit, 2023) | 1.47 | (Huang et al., 2024a, Table 1) |
| 2DGS-15k (Ours)本方法原文提出 | 0.48 | (Huang et al., 2024a, Table 1) |
| 2DGS-30k (Ours)本方法原文提出 | 0.48 | (Huang et al., 2024a, Table 1) |
Huang et al., 2024a · Table 2 本方法 8 筆
表格設定(擷取紀錄原文):F1 score per Tanks and Temples scene and mean; distance threshold not stated in the paper (TnT benchmark protocol) (Huang et al., 2024a, Table 2)
F1 score,Tanks and Temples · Barn
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Huang et al., 2024a 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Huang et al., 2024a, Table 2)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| NeuS | 0.29 | (Huang et al., 2024a, Table 2) |
| Geo-Neus | 0.33 | (Huang et al., 2024a, Table 2) |
| Neurlangelo (as written; Neuralangelo) | 0.7 | (Huang et al., 2024a, Table 2) |
| SuGaR | 0.14 | (Huang et al., 2024a, Table 2) |
| 3DGS | 0.13 | (Huang et al., 2024a, Table 2) |
| Ours本方法原文提出 | 0.41 | (Huang et al., 2024a, Table 2) |
Qian et al., 2026 · Table 3 本方法 4 筆
資料集與序列Zhejiang shield tunnel UAV video (authors) · 80 m section, 210 images
表格設定(擷取紀錄原文):Modeling time per pipeline stage for the three mesh models on the same workstation; MVS dense stage run with GPU acceleration; face counts of Nos. 2 and 3 matched to No. 1 (about 10 million) via TSDF voxel size (Qian et al., 2026, Table 3)
Modeling time, Foundation: SfM (converted from h min s),Zhejiang shield tunnel UAV video (authors) · 80 m section, 210 images
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Qian et al., 2026 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Qian et al., 2026, Table 3)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| MVS + surface reconstruction (No. 1)硬體:Intel Core i9-14900KF, NVIDIA GeForce RTX 4080, 64 GB RAM, Windows 11 | 12.12 min | (Qian et al., 2026, Table 3) |
| 2DGS (no mask) + TSDF (No. 2)本方法硬體:Intel Core i9-14900KF, NVIDIA GeForce RTX 4080, 64 GB RAM, Windows 11 | 12.12 min | (Qian et al., 2026, Table 3) |
| 2DGS (mask) + TSDF (No. 3)原文提出硬體:Intel Core i9-14900KF, NVIDIA GeForce RTX 4080, 64 GB RAM, Windows 11 | 12.12 min | (Qian et al., 2026, Table 3) |
Qian et al., 2026 · Text Sec. Geometric Accuracy Evaluation 本方法 1 筆
指標Average point distance to model No. 1
資料集與序列Zhejiang shield tunnel UAV video (authors) · 80 m section
表格設定(擷取紀錄原文):Mean point-to-point distance from uniformly sampled mesh points of each 2DGS+TSDF model to the MVS+surface-reconstruction mesh (No. 1, designated reference); models have no absolute scale (unit u); registration method not stated (Qian et al., 2026, Text Sec. Geometric Accuracy Evaluation)
Average point distance to model No. 1,Zhejiang shield tunnel UAV video (authors) · 80 m section
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Qian et al., 2026 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Qian et al., 2026, Text Sec. Geometric Accuracy Evaluation)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| 2DGS (no mask) + TSDF (No. 2)本方法 | 0.09 | (Qian et al., 2026, Experimental Results, Geometric Accuracy Evaluation; Fig. 14 text) |
| 2DGS (mask) + TSDF (No. 3)原文提出 | 0.083 | (Qian et al., 2026, Experimental Results, Geometric Accuracy Evaluation; Fig. 14 text) |
來源
Huang et al., 2024a
(2024)2D Gaussian Splatting for Geometrically Accurate Radiance FieldsSpecial Interest Group on Computer Graphics and Interactive Techniques Conference Conference Papers (SIGGRAPH 2024), pp. 1-11
DOI 10.1145/3641519.3657428arXiv 2403.17888程式碼
同儕審查已出版已讀全文近十年
相關版本
- 預印本:arXiv:2403.17888 (comment: corrected Eq. 7) https://arxiv.org/abs/2403.17888
程式碼:https://github.com/hbb1/2d-gaussian-splatting(授權:Gaussian-Splatting License (non-commercial research use per LICENSE.md))。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。