LONER
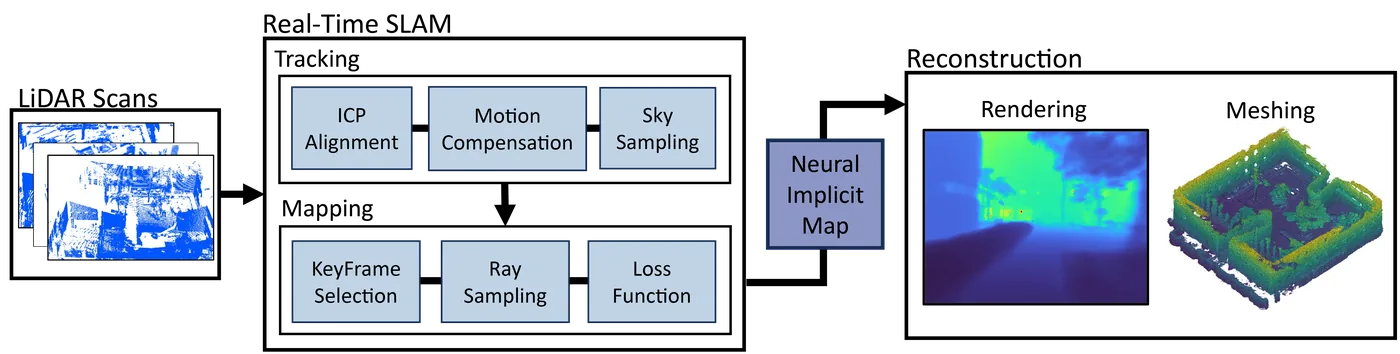
LONER 以點到平面 ICP(以單位矩陣為初始猜測,不使用 IMU)追蹤降採樣至 5 Hz 的 LiDAR 掃描,並在平行執行緒中以關鍵影格視窗(目前關鍵影格加上 7 個隨機選取的過去關鍵影格)聯合最佳化 MLP 與階層特徵格網地圖及關鍵影格位姿。其 JS 散度動態邊界損失依每條射線目前的學習程度調整目標分布寬度:尚未學好的區域用較大邊界以加快收斂,已學好的區域用較小邊界以保留細節。網格只在離線時以虛擬 LiDAR 與 marching cubes 產生;評估時將網格取樣為點雲、降採樣,並把真值裁切至感測器實際觀測範圍。
本頁內容
Real-time LiDAR-only SLAM with ICP tracking and a neural implicit map trained with an information-theoretic dynamic-margin loss.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | 3D LiDAR |
|---|---|
| 原文測試平台 | handheld、legged |
| 狀態估計 | point-to-plane ICP tracking (identity initial guess, no IMU) + joint optimization of MLP map and keyframe poses in a window |
| 資料關聯 | point-to-plane ICP for tracking; depth-supervised neural rendering with a JS-divergence dynamic-margin loss for mapping |
| 時間表示 | discrete poses |
| 去畸變 | constant-velocity motion compensation between scans (Sec. III-B) |
| 迴圈閉合 | none reported |
| 全域最佳化 | none |
| 地圖表示 | MLP with the hierarchical feature-grid encoding of ref. [26] (Instant-NGP multiresolution hash encoding) predicting volume density only, no colour (Sec. III-C) |
| 先驗資訊 | none |
| 可輸出幾何 | mesh generated offline by virtual LiDAR rays + marching cubes (not part of online training) |
| 計算需求 | AMD Ryzen 5950X CPU + NVIDIA A6000 GPU; tracking about 14 ms per step at the 5 Hz decimated scan rate; mapping 50 iterations per KeyFrame (one KeyFrame every 3 s) taking 2.79 s on average, about 56 ms per iteration or about 18 Hz map updates (Sec. IV-E) |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
| LiDAR | LiDAR (model not named) | 方法輸入 | Fusion Portable; Newer College | only input sensor; scans decimated to 5 Hz; no IMU used (ICP starts from the identity) | (Isaacson et al., 2023, Abstract; Sec. III-A, III-B; Sec. IV-C) |
| 相機 | monochrome fisheye cameras (model not named) | 資料集感測器 | Newer College | reason NICE-SLAM could not be run on Newer College | (Isaacson et al., 2023, Sec. IV-C) |
| 雙目相機 | stereo camera (model not named) | 資料集感測器 | Fusion Portable | used offline with RAFT optical flow to simulate RGB-D input for the NICE-SLAM baseline | (Isaacson et al., 2023, Sec. IV-C) |
| 載具平台 | quadruped (model not named) | 資料集感測器 | Fusion Portable | carried the sensors for MCR Slow 01, a small indoor lab scene | (Isaacson et al., 2023, Sec. IV-C) |
| 載具平台 | handheld platform (not named) | 資料集感測器 | Fusion Portable | Canteen Day and Garden Day, medium-scale semi-outdoor courtyards | (Isaacson et al., 2023, Sec. IV-C) |
| 運算硬體 | AMD Ryzen 5950X | 執行運算平台 | 未標示 | CPU | (Isaacson et al., 2023, Sec. IV-E) |
| 運算硬體 | NVidia A6000 | 執行運算平台 | 未標示 | GPU | (Isaacson et al., 2023, Sec. IV-E) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
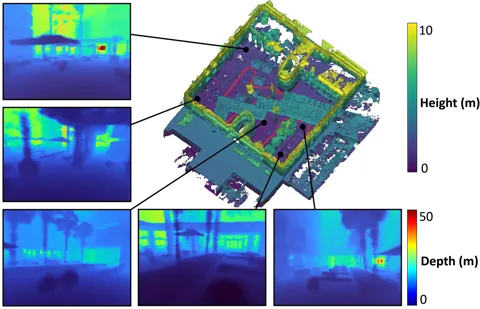
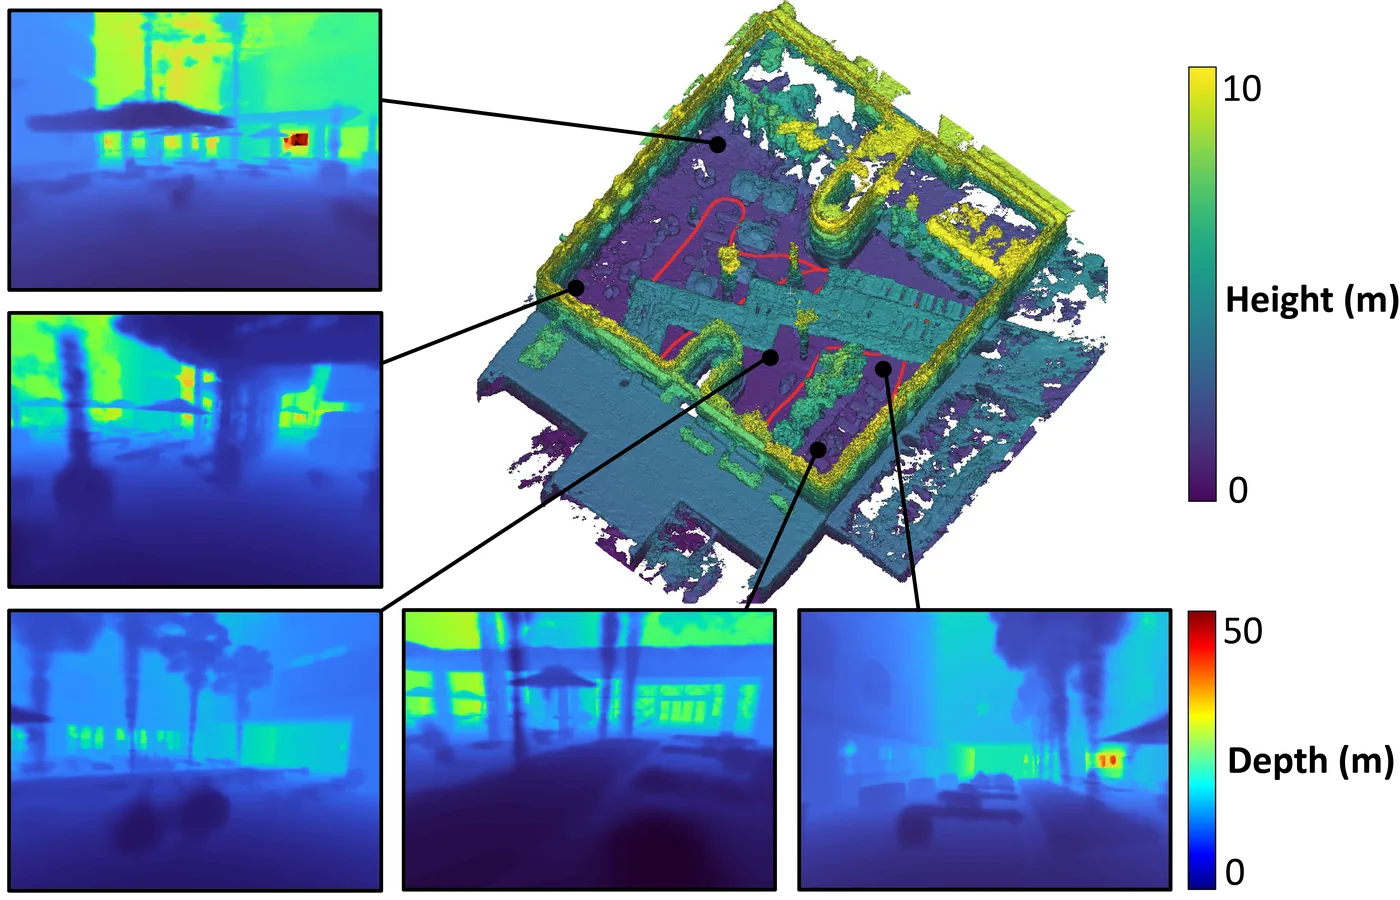
Fig. 1Fusion Portable 庭院場景的 LONER 網格重建與估計軌跡(紅線),周圍為訓練軌跡以外新視角渲染的深度影像
出處:Isaacson et al., 2023,Fig. 1。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
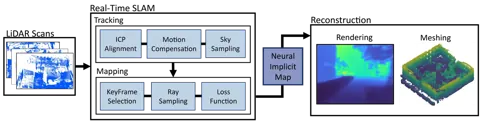
Fig. 2系統總覽:掃描降採樣後以 ICP 追蹤、分割天空、選取關鍵影格,並以新損失同時更新位姿與 MLP,地圖可離線渲染為深度影像或網格
出處:Isaacson et al., 2023,Fig. 2。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
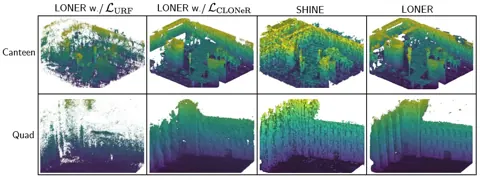
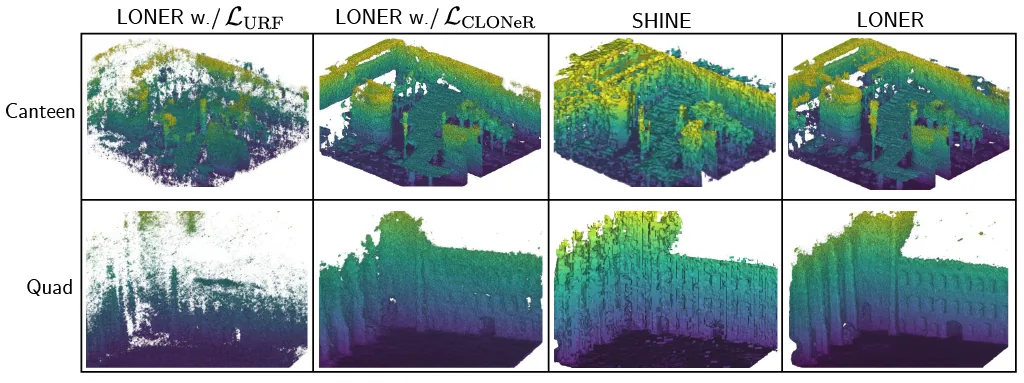
Fig. 5四個序列上 NICE-SLAM、SHINE、LONER 各損失版本的網格重建比較
出處:Isaacson et al., 2023,Fig. 5。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
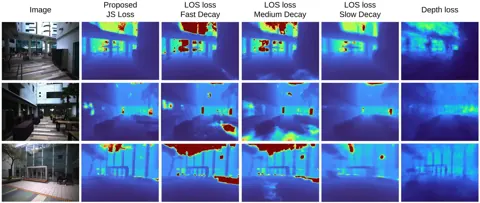
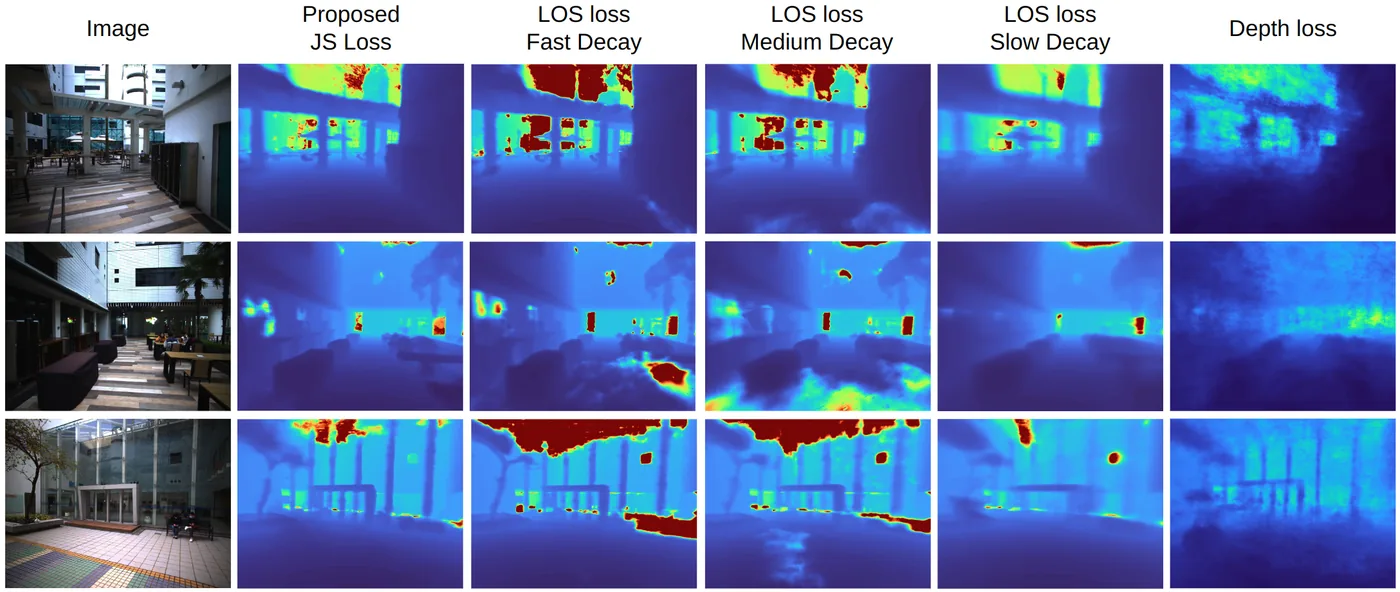
Fig. 6以不同損失訓練的 MLP 所渲染的深度影像,比較補洞能力與幾何細節
出處:Isaacson et al., 2023,Fig. 6。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Lower RMS APE than LeGO-LOAM on MCR, Canteen and Garden (0.029, 0.064, 0.056 m vs 0.052, 0.129, 0.161 m); on Newer College Quad LeGO-LOAM is 4 mm better (0.126 vs 0.130 m) (Table II)
- Best completion on MCR and Canteen and best recall at 0.1 m on Canteen, Garden and Quad among the compared methods (Table III)
- JS dynamic-margin loss converged faster than LOS and depth losses on a single simulated CARLA scan (Fig. 4), and the full loss gave the lowest or tied-lowest APE and L1 depth on every sequence in the loss ablation (Garden APE tied at 0.056 m with the LOS plus dynamic-margin row) (Table V)
- Real-time operation: tracking 14 ms per step and each KeyFrame processed within its 3 s budget (Sec. IV-E)
限制
- No IMU; rapid rotation and feature-sparse scenes are future work (Sec. V)
- Dynamic objects not handled (Sec. V)
- City-scale operation not yet addressed (Sec. V)
- Sky segmentation heuristic assumes the LiDAR is approximately level at initialization (Sec. III-E3)
- SHINE Mapping, run with ground-truth poses, had better map accuracy on MCR and Quad and better completion on Garden and Quad than LONER (Table III)
- Accuracy and precision were not reported for Canteen and Garden ('-', invalid configuration), so map quality there rests on completion and recall only (Table III)
- Map metrics use voxel-downsampled clouds (5 cm, 1 cm for MCR) against ground truth cropped to observed geometry, so unobserved areas do not count against completeness (Sec. IV-D2)
營建工程相關證據
論文未在營建場域測試;資料為 Fusion Portable(四足實驗室、手持校園庭院)與 Newer College Quad。
原文驗證環境:公開基準、模擬
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 3 個比較組,合計 24 筆紀錄。
Isaacson et al., 2023 · Table III 本方法 16 筆
表格設定(擷取紀錄原文):Map accuracy and completion (m, mean nearest-point distances) and precision and recall at a 0.1 m threshold; meshes from each method sampled to point clouds, all clouds voxel-downsampled to 5 cm (1 cm for MCR), ground truth cropped to geometry observed by the sensor. SHINE Mapping used ground-truth poses. '-' = invalid configuration (accuracy and precision are '-' for every method on Canteen and Garden; NICE-SLAM '-' on Quad), x = failed (NICE-SLAM on Canteen and Garden, all metrics). (Isaacson et al., 2023, Table III)
Accuracy (mean distance estimated to ground truth),Fusion Portable · MCR Slow 01
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Isaacson et al., 2023 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Isaacson et al., 2023, Table III)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| NICE-SLAM | 0.621 m | (Isaacson et al., 2023, Table III) |
| SHINE (ground-truth poses) | 0.164 m | (Isaacson et al., 2023, Table III) |
| LONER w./ L_CLONeR | 0.11 m | (Isaacson et al., 2023, Table III) |
| LONER w./ L_URF | 0.153 m | (Isaacson et al., 2023, Table III) |
| LONER本方法原文提出 | 0.186 m | (Isaacson et al., 2023, Table III) |
Isaacson et al., 2023 · Table II 本方法 4 筆
指標RMS APE (t_APE)
表格設定(擷取紀錄原文):RMS APE (m), median of 5 runs per method; trajectories aligned following Zhang and Scaramuzza [30] with evo (alignment type not stated); x = failed; '-' = not run (NICE-SLAM needs RGB-D and Newer College has monochrome fisheye cameras). NICE-SLAM ran offline on RGB-D simulated from stereo with RAFT, 350 iterations per KeyFrame; it succeeded on MCR in 4 of 5 runs. (Isaacson et al., 2023, Table II)
RMS APE (t_APE),Fusion Portable · MCR Slow 01
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Isaacson et al., 2023 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Isaacson et al., 2023, Table II)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| LeGO-LOAM | 0.052 m | (Isaacson et al., 2023, Table II) |
| NICE-SLAM | 0.248 m | (Isaacson et al., 2023, Table II) |
| LONER w./ L_URF | 0.047 m | (Isaacson et al., 2023, Table II) |
| LONER w./ L_CLONeR | 0.034 m | (Isaacson et al., 2023, Table II) |
| LONER本方法原文提出 | 0.029 m | (Isaacson et al., 2023, Table II) |
Isaacson et al., 2023 · Text Sec.IV-E 本方法 4 筆
資料集與序列原文未報告 · 原文未報告 (Sec. IV-E does not name the sequence used for timing)
表格設定(擷取紀錄原文):Runtime of LONER in real-time configuration (scans decimated to 5 Hz, one KeyFrame every 3 s, 50 iterations per KeyFrame). (Isaacson et al., 2023, Text Sec.IV-E)
average time per tracking step,原文未報告 · 原文未報告 (Sec. IV-E does not name the sequence used for timing)
這張表在此指標與資料序列只列出本方法一筆,沒有可並列的其他方法,因此不畫圖,數值與出處見下表。這是 Isaacson et al., 2023 在此表設定下報告的數值(author-reported results),不代表方法在其他資料或設定下的表現。
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| LONER本方法原文提出硬體:AMD Ryzen 5950X CPU + NVIDIA A6000 GPU | 14 ms | (Isaacson et al., 2023, Sec. IV-E) |
來源
Isaacson et al., 2023
(2023)LONER: LiDAR Only Neural Representations for Real-Time SLAMIEEE Robotics and Automation Letters, 8(12), 8042-8049
DOI 10.1109/lra.2023.3324521arXiv 2309.04937程式碼
同儕審查已出版已讀全文近十年查證後修正
相關版本
- 預印本:arXiv:2309.04937 https://arxiv.org/abs/2309.04937
程式碼:https://github.com/umautobots/LONER(授權:CC BY-NC-SA 4.0)。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。