CT-ICP
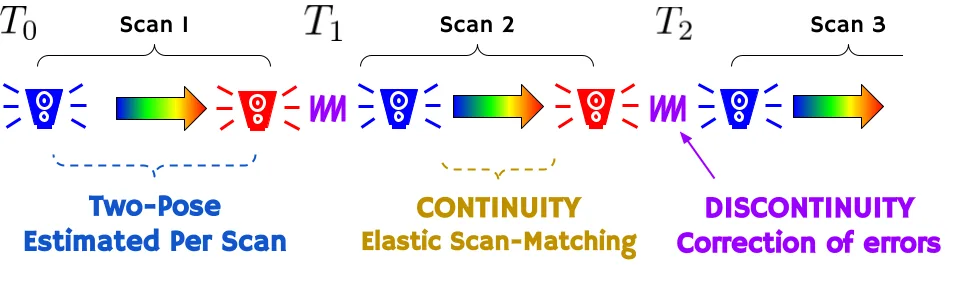
CT-ICP 以每次掃描的起始與結束兩個位姿參數化掃描內的連續時間軌跡,在點到平面 ICP 中同時估計扭曲,使掃描可「彈性」變形;掃描之間允許不連續,並以位置一致與等速兩項約束抑制過度跳動。地圖為稀疏體素中的稠密點雲。作者再以局部地圖投影成高程影像的迴圈偵測與 g2o 位姿圖構成完整 SLAM,但此迴圈方法假設運動大致在平面上。
本頁內容
LiDAR-only odometry that estimates begin and end poses per scan inside point-to-plane ICP (continuous within, discontinuous between scans), completed into SLAM with elevation-image loop detection and a pose graph.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | 3D LiDAR only (xyz plus per-point timestamps) |
|---|---|
| 原文測試平台 | vehicle、handheld、wheeled UGV、simulation |
| 狀態估計 | scan-to-map continuous-time ICP (robust loss, iterative least squares) over two poses per scan with location-consistency and constant-velocity regularizers; g2o pose-graph back-end |
| 資料關聯 | point-to-plane to dense local map, normals and planarity weights from k=20 neighbours in 27 surrounding voxels |
| 時間表示 | continuous within a scan (linear translation and slerp rotation between begin and end poses), discontinuous between scans |
| 去畸變 | elastic: scan distortion estimated jointly with registration |
| 迴圈閉合 | elevation images of aggregated local maps with rotation-invariant 2D features, RANSAC and ICP refinement; requires mostly planar ground motion and z-axis aligned with ground normal |
| 全域最佳化 | pose graph (g2o) optimized only when a loop constraint is detected |
| 地圖表示 | dense point cloud in a sparse voxel grid (max 20 points per voxel, 10 cm minimum spacing; voxel 1.0 m driving, 0.8 m high-frequency motion) |
| 先驗資訊 | none |
| 可輸出幾何 | trajectory and aggregated point clouds (Fig. 2); export format 原文未報告 |
| 計算需求 | single-thread CPU by default (model not reported); average 60 ms per scan on the KITTI leaderboard submission (abstract); Table I average time per scan 60 to 80 ms with the Driving profile, but 430 ms on NCD and 180 ms on NCLT with the High-Frequency Motion (robust) profile; loop-closure elevation matching 1.1 s and PGO 1.2 s on average when triggered (Sec. V-C) |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
| LiDAR | Velodyne HDL64歸入:Velodyne HDL-64E | 資料集感測器 | KITTI / KITTI-raw / KITTI-360 | 64-beam, mounted on a car; KITTI-raw and KITTI-360 scans not motion-corrected, timestamps estimated from azimuth; 0.205 deg intrinsic angle correction applied | (Dellenbach et al., 2022, Sec. V-A-1) |
| LiDAR | simulated 64-channel LiDAR | 資料集感測器 | KITTI-CARLA | CARLA simulator, precise ground truth and timestamps | (Dellenbach et al., 2022, Sec. V-A-1) |
| LiDAR | Velodyne HDL32歸入:Velodyne HDL-32E | 資料集感測器 | ParisLuco | mounted vertically on the authors' vehicle; 4 km, 12751 scans in central Paris | (Dellenbach et al., 2022, Sec. V-A-1) |
| LiDAR | Velodyne HDL32歸入:Velodyne HDL-32E | 資料集感測器 | NCLT | mounted on a two-wheeled Segway | (Dellenbach et al., 2022, Sec. V-A-2) |
| LiDAR | Ouster 64-channel LiDAR | 資料集感測器 | Newer College Dataset (NCD) | handheld, mounted on a stick | (Dellenbach et al., 2022, Sec. V-A-2) |
| GNSS 接收器 | GPS/IMU (model not reported) | 參考或真值量測 | KITTI | ground-truth poses of KITTI | (Dellenbach et al., 2022, Sec. V-A-1) |
| GNSS 接收器 | GPS/IMU (post-processed; model not reported) | 參考或真值量測 | ParisLuco | ground truth translations only | (Dellenbach et al., 2022, Sec. V-A-1) |
| 載具平台 | two-wheeled Segway | 資料集感測器 | NCLT | abrupt rotations about the LiDAR axis | (Dellenbach et al., 2022, Sec. V-A-2) |
| 運算硬體 | CPU, single thread (model not reported) | 執行運算平台 | 未標示 | 原文未報告 | (Dellenbach et al., 2022, Abstract; Sec. III-A) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
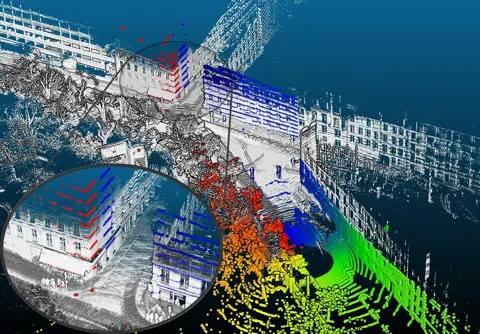
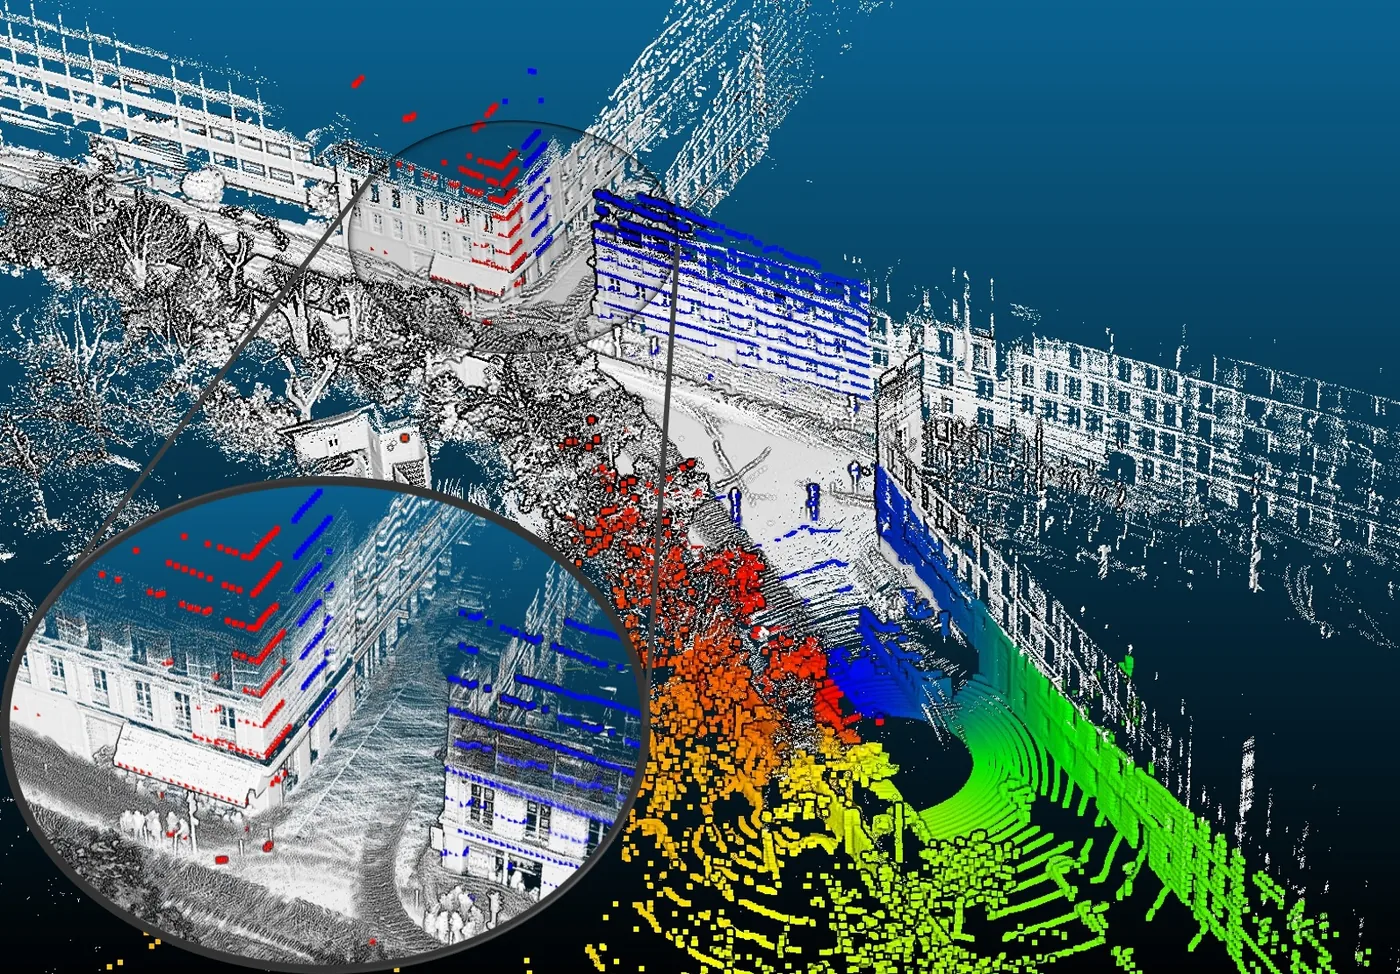
Fig. 1 (top)單次 LiDAR 掃描依各點時間戳記著色,經掃描起點與終點兩個位姿之間的彈性變形後對齊白色地圖點;下方軌跡示意見下一筆
出處:Dellenbach et al., 2022,Fig. 1 (top)。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
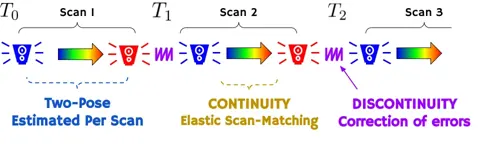
Fig. 1 (bottom)CT-ICP 軌跡參數化示意:每次掃描以起訖兩位姿內插,相鄰掃描之間允許不連續
出處:Dellenbach et al., 2022,Fig. 1 (bottom)。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
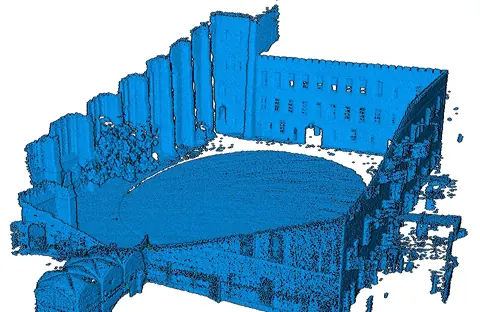
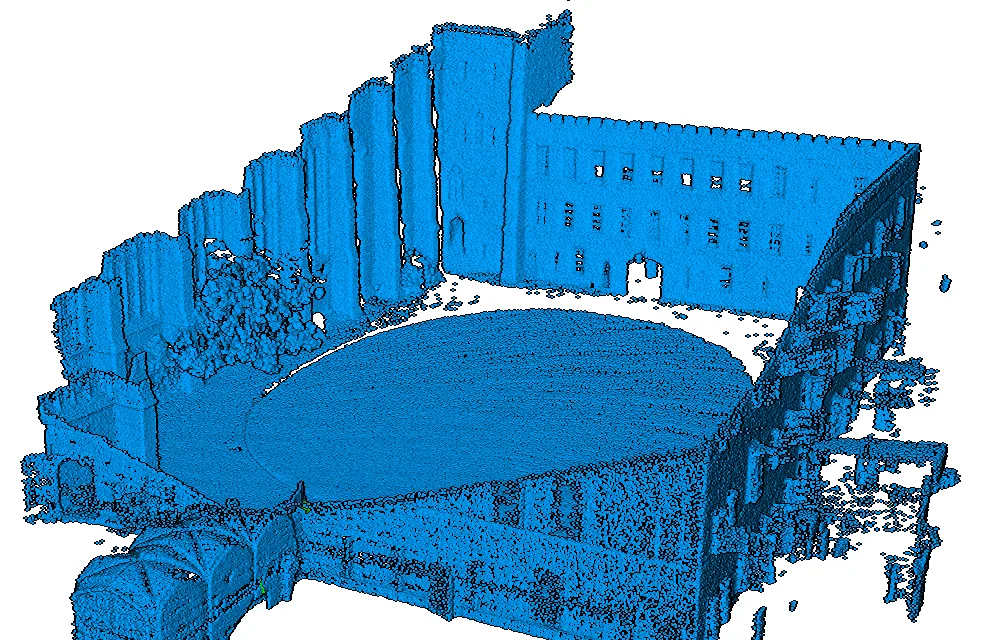
Fig. 2CT-ICP 在 NCLT、KITTI-CARLA、Newer College 與 ParisLuco 產生的累積點雲;連結為 Newer College 手持資料的子圖
出處:Dellenbach et al., 2022,Fig. 2。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
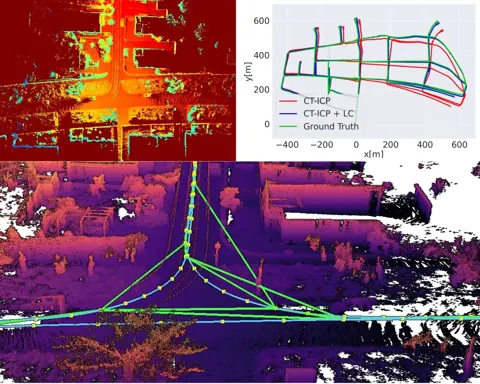
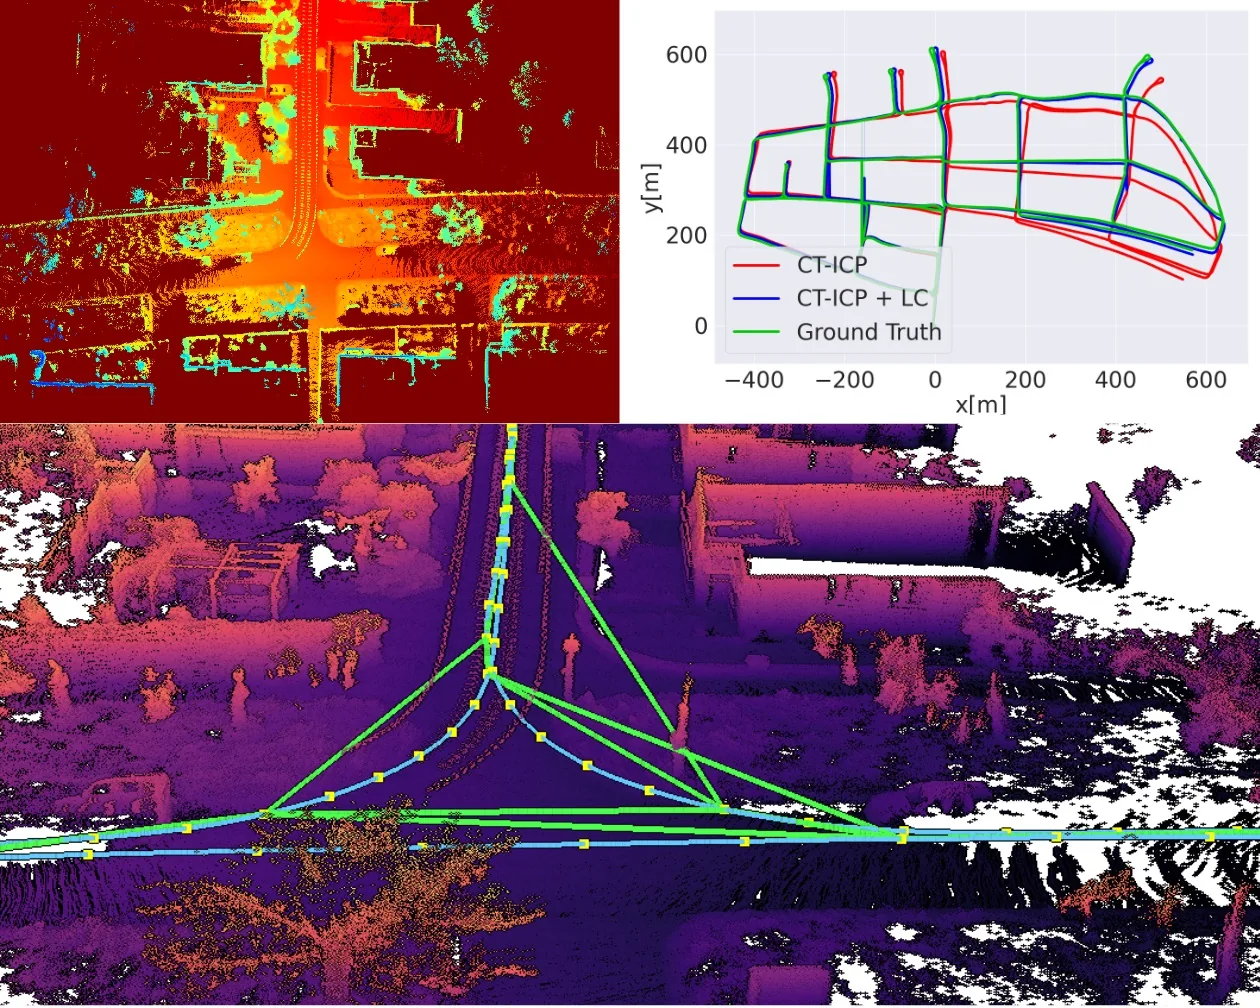
Fig. 4KITTI-360 序列 00 的迴圈閉合結果:局部地圖高程影像、修正前後軌跡與偵測到的迴圈約束
出處:Dellenbach et al., 2022,Fig. 4。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Elastic formulation handles raw (not pre-corrected) scans; replacing it by constant-velocity pre-deskew and a single pose raised KITTI-raw RTE from 0.55% to 0.79% (Sec. V-B)
- Robust profile retries registration with conservative parameters on hard cases (Sec. III-B)
- Lowest average RTE among compared odometries on all raw-scan datasets, e.g. KITTI-CARLA AVG 0.09% versus 0.81% for the best other method (Table I; Sec. V-B)
- Loop closure reduced mean ATE on KITTI-360 00 from 29.87 m to 1.07 m and on KITTI-raw 00 from 6.22 m to 0.66 m (Table II)
限制
- Loop closure requires mostly planar sensor motion and ground-aligned extrinsic calibration (Sec. IV)
- Robustness gain from the robust profile increases runtime (Sec. III-B)
- KISS-ICP authors could not reproduce CT-ICP NCLT results (KISS-ICP, Sec. IV-C)
- Traj-LO authors report CT-ICP failing on half of NTU VIRAL aerial sequences, attributing it to begin-end linear interpolation under rapid motion (Traj-LO, Sec. IV-B)
- Loop closure did not reduce mean ATE on KITTI-CARLA Town01 (0.21 to 0.26 m) or NCD 01_short_experiment (0.22 to 0.36 m) (Table II; table-derived)
- Authors list extending the continuous-time formulation to the back end as future work (Sec. VI)
營建工程相關證據
原文未報告(測試資料為道路、校園、手持與 Segway 資料集,未含施工現場)
原文驗證環境:公開基準、模擬
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 35 個比較組,合計 204 筆紀錄。以下列出本方法紀錄最多的 4 組,其餘 31 組列在最後,並連到性能比較頁。
Dellenbach et al., 2022 · Table I 本方法 42 筆
表格設定(擷取紀錄原文):KITTI RTE (%) averaged over segments of 100 to 800 m, Driving profile; AVG over all segments of all sequences; one parameter set per method for all driving datasets; scans are raw (not motion-corrected) except KITTI-corrected; per-sequence KITTI-corrected values omitted for row cap (Dellenbach et al., 2022, Table I)
Relative Translation Error (RTE),KITTI-corrected (motion-corrected odometry benchmark scans) · AVG
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Dellenbach et al., 2022 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Dellenbach et al., 2022, Table I)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| IMLS-SLAM [15] | 0.55% | (Dellenbach et al., 2022, Table I (Driving)) |
| MULLS [4] | 0.55% | (Dellenbach et al., 2022, Table I (Driving)) |
| pyLiDAR F2M [33] | 0.53% | (Dellenbach et al., 2022, Table I (Driving)) |
| CT-ICP (ours)本方法原文提出 | 0.53% | (Dellenbach et al., 2022, Table I (Driving)) |
Ferrari et al., 2024 · Table II 本方法 19 筆
表格設定(擷取紀錄原文):KITTI benchmark RPE (%); segments 100-800 m for KITTI, MulRan and NC1, 10-80 m for NC0 and Hilti; averages exclude failures; per-sequence KITTI 00-10 and MulRan rows omitted (averages kept); values identical in arXiv v1 and version of record (Ferrari et al., 2024, Table II)
RPE [%] (segments 10-80 m),Newer College NC0 (OS0-128) · cat. easy
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Ferrari et al., 2024 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Ferrari et al., 2024, Table II)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| Ours (MAD-ICP)原文提出 | 1.16% | (Ferrari et al., 2024, Table II) |
| KISS-ICP | 2.06% | (Ferrari et al., 2024, Table II) |
| F-LOAM | 1.36% | (Ferrari et al., 2024, Table II) |
| MULLS | 2% | (Ferrari et al., 2024, Table II) |
| CT-ICP本方法 | 1.12% | (Ferrari et al., 2024, Table II) |
Dellenbach et al., 2022 · Table II 本方法 12 筆
表格設定(擷取紀錄原文):Loop closure evaluation; mean ATE (m) after the best rigid transform between ground truth and estimate; Nmap=100, Noverlap=30; Nloop=69 loops detected (Dellenbach et al., 2022, Table II)
ATE (LO), mean Absolute Trajectory Error,KITTI-raw · 00
這張表在此指標與資料序列只列出本方法一筆,沒有可並列的其他方法,因此不畫圖,數值與出處見下表。這是 Dellenbach et al., 2022 在此表設定下報告的數值(author-reported results),不代表方法在其他資料或設定下的表現。
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| CT-ICP odometry only (LO)本方法原文提出 | 6.22 m | (Dellenbach et al., 2022, Table II) |
Liu et al., 2023b · Table II 本方法 12 筆
指標RMSE of the ATE, translation part of deg/m pair
表格設定(擷取紀錄原文):KITTI with loop-closed MULLS poses as HBA input; RMSE of ATE printed as rotation (deg)/translation (m); only the translation part is extracted; the '(loops)' sequence labels follow the asterisks of arXiv v1 Table II (the version-of-record table image carries no asterisks); version of record adds CT-ICP and LOAM rows (Liu et al., 2023b, Table II)
RMSE of the ATE, translation part of deg/m pair,KITTI · Seq. 00 (loops)
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Liu et al., 2023b 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Liu et al., 2023b, Table II)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| Proposed原文提出 | 0.8 m | (Liu et al., 2023b, Table II (version of record)) |
| CT-ICP本方法 | 1.7 m | (Liu et al., 2023b, Table II (version of record)) |
| MULLS | 1.1 m | (Liu et al., 2023b, Table II (version of record)) |
| LiTAMIN2 | 1.3 m | (Liu et al., 2023b, Table II (version of record)) |
| SuMa | 1 m | (Liu et al., 2023b, Table II (version of record)) |
| LOAM | 1.5 m | (Liu et al., 2023b, Table II (version of record)) |
其他比較組
列出其餘 31 個比較組
- Liu et al., 2023b · Table V
- Zheng & Zhu, 2024 · Table I
- Zheng & Zhu, 2024 · Table III
- Guadagnino et al., 2025a · Table III
- Chen et al., 2023 · Table II
- Guadagnino et al., 2025a · Table IV
- Guadagnino et al., 2025a · Table V
- Chen et al., 2023 · Table I
- Lee et al., 2025a · Table V
- Guadagnino et al., 2025a · Table II
- Vizzo et al., 2023 · Table IV
- Blanco-Claraco, 2025 · Table 3
- Burnett et al., 2025 · Table I
- Dellenbach et al., 2022 · Text Abstract
- Dellenbach et al., 2022 · Text Sec.V-B
- Dellenbach et al., 2022 · Text Sec.V-C
- Lee et al., 2025a · Table I
- Lee et al., 2025a · Table VI
- Helmberger et al., 2022 · Table III
- Vizzo et al., 2023 · Table II
- Vizzo et al., 2023 · Table V
- Burnett et al., 2025 · Table II
- Zheng & Zhu, 2024 · Table V
- Zhang et al., 2023c · Table II
- Liu et al., 2023a · Supplementary Table VII
- Lee et al., 2025a · Table III
- Lee et al., 2025a · Table IV
- Liu et al., 2023b · Table IV
- Guadagnino et al., 2025a · Table I
- Ferrari et al., 2024 · Table III
- Zhang et al., 2024a · Table 8
來源
Dellenbach et al., 2022
(2022)CT-ICP: Real-time Elastic LiDAR Odometry with Loop Closure2022 International Conference on Robotics and Automation (ICRA), pp. 5580-5586
DOI 10.1109/icra46639.2022.9811849arXiv 2109.12979程式碼
同儕審查已出版已讀全文近十年
相關版本
- 預印本:CT-ICP: Real-time Elastic LiDAR Odometry with Loop Closure (arXiv v2) https://arxiv.org/abs/2109.12979
- 程式碼釋出:jedeschaud/ct_icp; loop closure integrated in Kitware/pyLiDAR-SLAM https://github.com/jedeschaud/ct_icp
程式碼:https://github.com/jedeschaud/ct_icp(授權:MIT (LICENSE file checked))。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。