COIN-LIO
COIN-LIO 以 FAST-LIO2 的點到平面配準為基礎,將 LiDAR 強度回波投影為強度影像並做亮度一致化濾波,再把影像區塊的光度誤差(photometric error)一併放入迭代擴展卡爾曼濾波。作者偵測點雲配準中資訊不足的方向,刻意挑選能在該方向提供互補資訊的影像區塊,以改善隧道、平坦場地等幾何退化場景的穩健性。作者並公開以全測站量測地面真值的 ENWIDE 退化場景資料集。
本頁內容
Augments FAST-LIO2 with photometric residuals on filtered LiDAR intensity images, selecting patches that constrain geometrically uninformative directions, to improve robustness in tunnels and flat fields.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | high-resolution 3D LiDAR with intensity (Ouster OS0-128)、IMU |
|---|---|
| 原文測試平台 | handheld |
| 狀態估計 | iterated extended Kalman filter built on FAST-LIO2, fusing IMU, point-to-plane registration and photometric error on intensity-image patches |
| 資料關聯 | point-to-plane geometry plus photometric patch residuals on brightness-filtered intensity images; patches selected to be informative in directions where geometry is uninformative |
| 時間表示 | discrete poses (as FAST-LIO2) |
| 去畸變 | IMU-propagated undistortion of each point to the scan-end time as in FAST-LIO2 (Sec. III-B); for photometric residuals, tracked points are projected into the distorted LiDAR frame using a projection-based undistortion map that returns each pixel's point index and timestamp (Sec. III-G) |
| 迴圈閉合 | none |
| 全域最佳化 | none |
| 地圖表示 | ikd-Tree point map inherited from FAST-LIO2 plus a feature map of tracked 5 x 5 intensity patches whose pixels are each initialised at their own global 3D position |
| 先驗資訊 | none |
| 可輸出幾何 | odometry and point map; export format 原文未報告 |
| 計算需求 | CPU real time; on average 29.7 ms per frame (33 Hz) on an Intel i7-11800H mobile CPU on the Newer College Park sequence, of which 6.2 ms is spent on the photometric components |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
| LiDAR | Ouster OS0 | 方法輸入 | ENWIDE | 128 beam, hand-held, with integrated IMU; intensity returns projected into images | (Pfreundschuh et al., 2024, Sec. IV-B) |
| LiDAR | Ouster OS0 | 資料集感測器 | Newer College Dataset (multi-camera extension) | 128-beam, hand-held | (Pfreundschuh et al., 2024, Sec. IV-A) |
| 慣性量測單元(IMU) | Ouster OS0 integrated IMU (model not reported) | 方法輸入 | ENWIDE | 原文未報告 | (Pfreundschuh et al., 2024, Sec. IV-B) |
| 全測站 | Leica MS60 | 參考或真值量測 | ENWIDE | ground-truth positions with approximately 3 cm accuracy | (Pfreundschuh et al., 2024, Sec. IV-B) |
| 載具平台 | hand-held rig (not further described) | 方法輸入 | ENWIDE | walking (smooth) and running (dynamic) sequences | (Pfreundschuh et al., 2024, Sec. IV-B) |
| 運算硬體 | Intel i7-11800H | 執行運算平台 | 未標示 | mobile CPU | (Pfreundschuh et al., 2024, Sec. IV-A) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
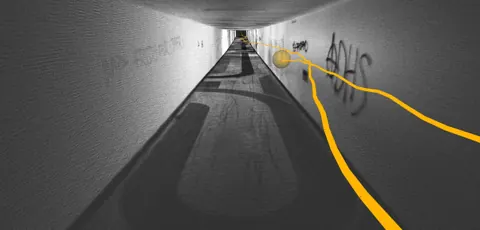
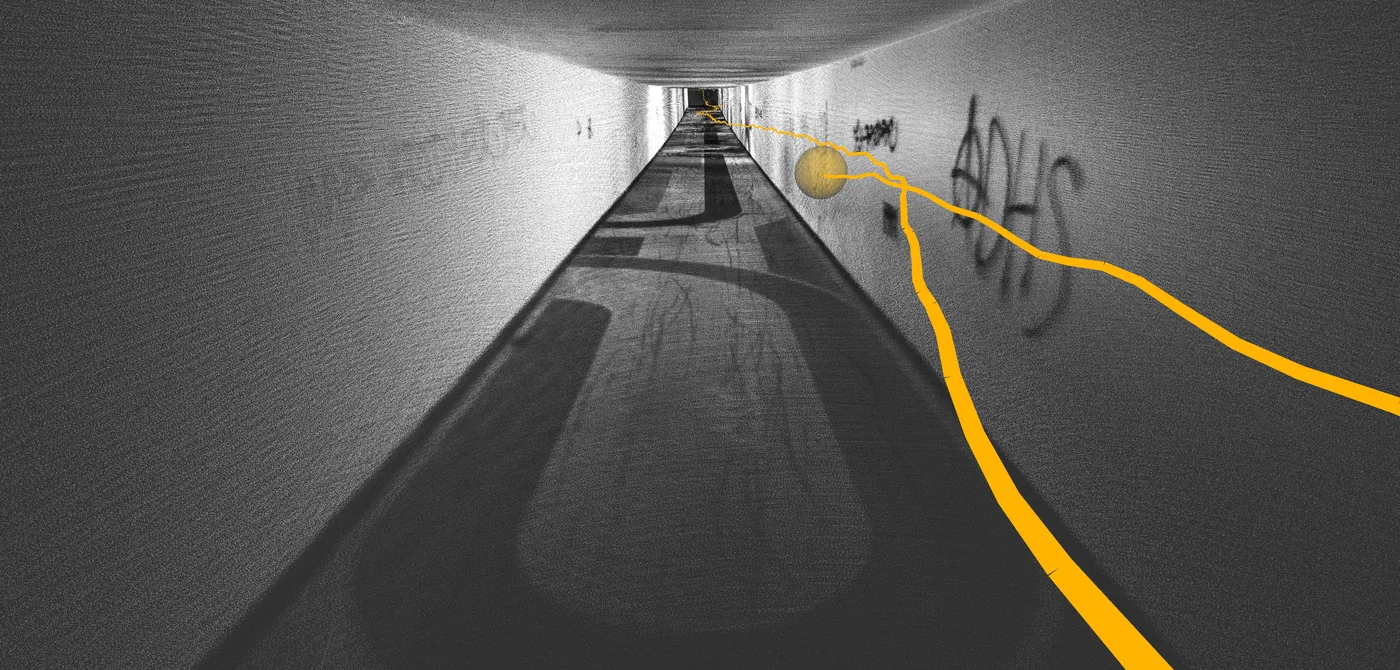
Fig. 1隧道場景的累積點雲依強度著色並疊加 COIN-LIO 軌跡;連結僅為 Fig. 1 上方子圖,中段的追蹤特徵與下方俯視點雲為另外的子圖
出處:Pfreundschuh et al., 2024,Fig. 1。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
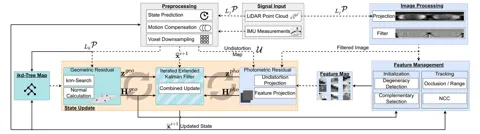
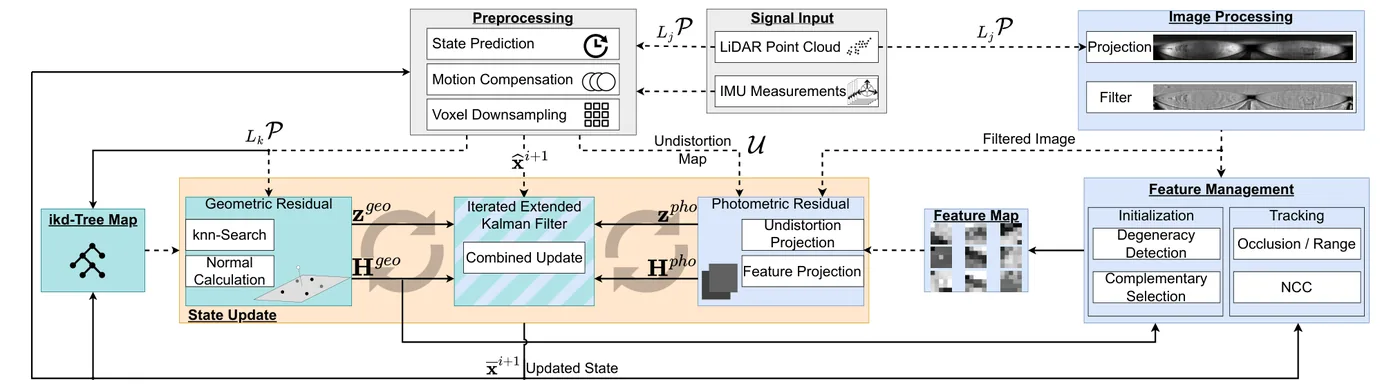
Fig. 2系統架構圖:點雲同時用於幾何配準與投影強度影像的光度誤差,兩種殘差在迭代擴展卡爾曼濾波中合併更新
出處:Pfreundschuh et al., 2024,Fig. 2。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
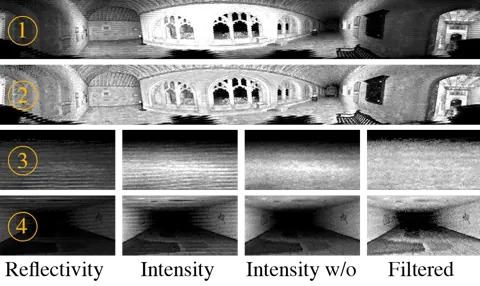
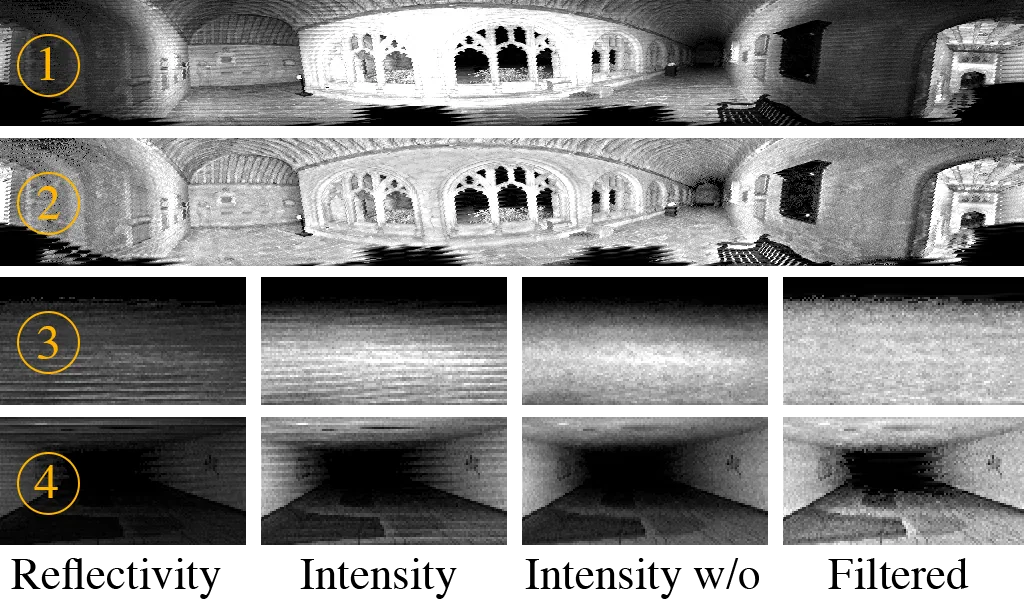
Fig. 4原始強度影像、反射率影像與本文濾波影像的比較,含草地與隧道的局部放大
出處:Pfreundschuh et al., 2024,Fig. 4。授權:CC BY 4.0。原始圖檔。修改:轉存為 WebP 格式。
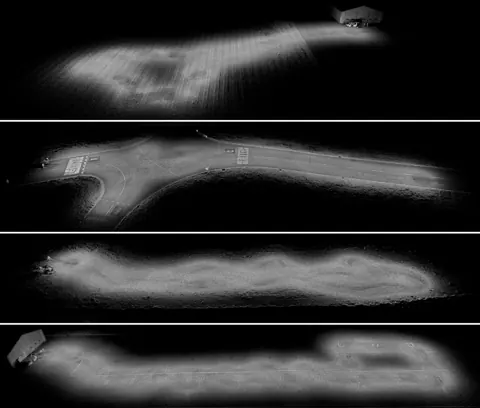
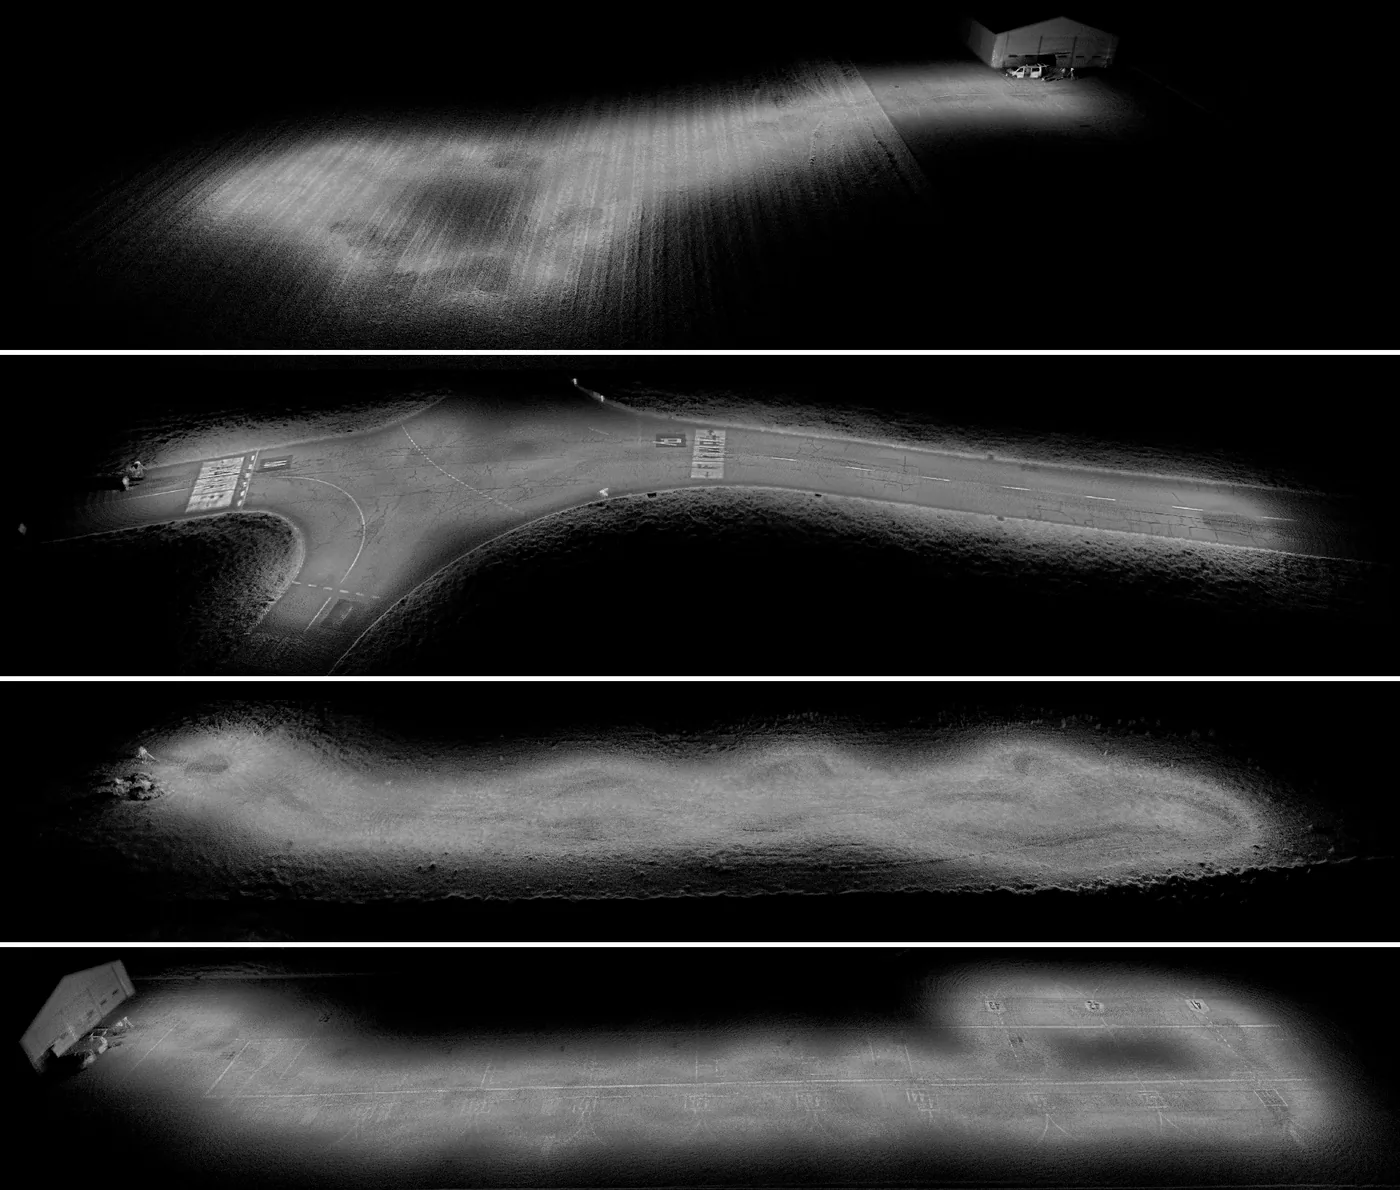
Fig. 6COIN-LIO 在 ENWIDE 的 FieldS、IntersectionS、KatzenseeS 與 RunwayS 所建立的點雲地圖
出處:Pfreundschuh et al., 2024,Fig. 6。授權:CC BY 4.0。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Drastically improved robustness on ENWIDE degenerate sequences where compared baselines fail or drift (Sec. IV-C)
- Slightly better than baselines on geometry-rich Newer College (Sec. V)
- Only compared method without a failure mark on all ten ENWIDE sequences; on Newer College Stairs only COIN-LIO and MD-SLAM avoided failure, with COIN-LIO at 0.102 m versus 0.340 m ATE (Tables I and II)
- Ablation: filtered images with geometrically complementary patch selection gave the lowest ATE on all three ablation sequences (Table III)
限制
- Requires high-resolution LiDARs to form dense intensity images (Sec. V)
- LIO approaches can still fail over long degenerate segments due to IMU noise and bias drift (Sec. IV-C, discussing baselines)
營建工程相關證據
ENWIDE 以手持 Ouster OS0-128 錄製五種場景:Tunnel(城市、室內)、Intersection(城市、戶外)、Runway(戶外、城市)、Field 與 Katzensee(戶外、自然環境);地面真值由 Leica MS60 全測站量測,約 3 cm 精度。隧道情境與地下工程相關(推論),但非施工中工地。
原文驗證環境:公開基準、地下或隧道、獨立參考量測
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 9 個比較組,合計 75 筆紀錄。以下列出本方法紀錄最多的 4 組,其餘 5 組列在最後,並連到性能比較頁。
Pfreundschuh et al., 2024 · Table II 本方法 20 筆
表格設定(擷取紀錄原文):ENWIDE dataset, hand-held Ouster OS0-128 with integrated IMU; ground-truth positions from Leica MS60 (about 3 cm); ATE RMSE (m) / RTE (%) over 10 m segments; RTE > 20% declared failed (x); RTE rows kept only for non-failed cells, failed-cell RTE is in the ATE row outcome (Pfreundschuh et al., 2024, Table II)
Absolute Trajectory Error (RMSE),ENWIDE · TunnelS (251.58 m)
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 失敗
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Pfreundschuh et al., 2024 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Pfreundschuh et al., 2024, Table II)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| KISS-ICP [10] | 無數值失敗註記(擷取紀錄):failed (marked x; RTE 144.41%) | (Pfreundschuh et al., 2024, Table II) |
| MD-SLAM [6] | 無數值失敗註記(擷取紀錄):failed (marked x; RTE 88.16%) | (Pfreundschuh et al., 2024, Table II) |
| Du and Beltrame [8] | 無數值失敗註記(擷取紀錄):failed (marked x; RTE 58.084%) | (Pfreundschuh et al., 2024, Table II) |
| LIO-SAM [12] | 無數值失敗註記(擷取紀錄):failed (marked x; RTE 2565.621%) | (Pfreundschuh et al., 2024, Table II) |
| FAST-LIO2 [1] | 無數值失敗註記(擷取紀錄):failed (marked x; RTE 316.12%) | (Pfreundschuh et al., 2024, Table II) |
| RI-LIO [7] | 無數值失敗註記(擷取紀錄):failed (marked x; RTE 70.32%) | (Pfreundschuh et al., 2024, Table II) |
| Ours (COIN-LIO)本方法原文提出 | 0.743 m | (Pfreundschuh et al., 2024, Table II) |
Chen et al., 2025b · Table 5 本方法 15 筆
指標ATE (m)
表格設定(擷取紀錄原文):ATE (m) per sequence, average of five runs, parameters not tuned per sequence; X = breakdown or error > 100 m; - = algorithm not adapted to this data. Only Metro tunnels and Stairs blocks extracted; shield-tunnel sequences are absent from Table 5 because all methods failed (Sec. 5.2). Stairs GT from PALoc (inlier RMSE 0.07 m alpha, 0.08 m beta); gamma stairs GT not accurate. (Chen et al., 2025b, Table 5)
ATE (m),GEODE · Metro tunnels, alpha (Velodyne VLP-16), Tunneling 3
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 不適用
- 失敗
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Chen et al., 2025b 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Chen et al., 2025b, Table 5)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| COIN-LIO本方法 | 無數值不適用註記(擷取紀錄):不適用 | (Chen et al., 2025b, Table 5 (VoR)) |
| FAST-LIO2 | 0.21 m | (Chen et al., 2025b, Table 5 (VoR)) |
| DLIO | 0.18 m | (Chen et al., 2025b, Table 5 (VoR)) |
| FAST-LIVO | 0.2 m | (Chen et al., 2025b, Table 5 (VoR)) |
| Coco-LIC | 無數值不適用註記(擷取紀錄):不適用 | (Chen et al., 2025b, Table 5 (VoR)) |
| R3LIVE | 0.59 m | (Chen et al., 2025b, Table 5 (VoR)) |
| LVI-SAM | 無數值失敗註記(擷取紀錄):failed | (Chen et al., 2025b, Table 5 (VoR)) |
| VINS-Fusion | 47.66 m | (Chen et al., 2025b, Table 5 (VoR)) |
Pfreundschuh et al., 2024 · Table III 本方法 15 筆
指標Absolute Trajectory Error (RMSE)
表格設定(擷取紀錄原文):Ablation of COIN-LIO image type and patch selection policy on ENWIDE; ATE RMSE (m); x = failed (Pfreundschuh et al., 2024, Table III)
Absolute Trajectory Error (RMSE),ENWIDE · TunnelD
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 失敗
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Pfreundschuh et al., 2024 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Pfreundschuh et al., 2024, Table III)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| COIN-LIO ablation: Intensity image + Strongest-gradient features本方法 | 13.928 m | (Pfreundschuh et al., 2024, Table III) |
| COIN-LIO ablation: Reflectivity image + Strongest-gradient features本方法 | 無數值失敗註記(擷取紀錄):failed (marked x) | (Pfreundschuh et al., 2024, Table III) |
| COIN-LIO ablation: Filtered image + Strongest-gradient features本方法 | 0.814 m | (Pfreundschuh et al., 2024, Table III) |
| COIN-LIO ablation: Filtered image + Random features本方法 | 1.913 m | (Pfreundschuh et al., 2024, Table III) |
| COIN-LIO ablation: Filtered image + Complementary features (proposed)本方法原文提出 | 0.487 m | (Pfreundschuh et al., 2024, Table III) |
Yan et al., 2026a · Table 1 本方法 9 筆
表格設定(擷取紀錄原文):ATE (RMSE, m) on KMCT; each ROS bag run five times and the best trial reported; 'Failed' = failure to run (Yan et al., 2026a, Table 1)
ATE (m), RMSE of global absolute trajectory error,Kimera-Multi Campus-Tunnel (KMCT) · 07_ac2-005
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 失敗
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Yan et al., 2026a 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Yan et al., 2026a, Table 1)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| ORB-SLAM3 | 無數值失敗註記(擷取紀錄):failed | (Yan et al., 2026a, Table 1) |
| VINS-Mono | 3.96 m | (Yan et al., 2026a, Table 1) |
| LeGO-LOAM | 3.63 m | (Yan et al., 2026a, Table 1) |
| LIO-SAM | 3.41 m | (Yan et al., 2026a, Table 1) |
| Fast-LIO2 | 2.7 m | (Yan et al., 2026a, Table 1) |
| LVI-SAM | 2.77 m | (Yan et al., 2026a, Table 1) |
| COIN-LIO本方法 | 2.71 m | (Yan et al., 2026a, Table 1) |
| VINS-FEN | 3.05 m | (Yan et al., 2026a, Table 1) |
| Proposed原文提出 | 2.89 m | (Yan et al., 2026a, Table 1) |
其他比較組
來源
Pfreundschuh et al., 2024
(2024)COIN-LIO: Complementary Intensity-Augmented LiDAR Inertial Odometry2024 IEEE International Conference on Robotics and Automation (ICRA), pp. 1730-1737
DOI 10.1109/icra57147.2024.10610938arXiv 2310.01235程式碼
同儕審查已出版已讀全文近十年查證後修正
相關版本
- 預印本:COIN-LIO (arXiv v4, journal ref ICRA 2024) https://arxiv.org/abs/2310.01235
- 程式碼釋出:ethz-asl/COIN-LIO https://github.com/ethz-asl/COIN-LIO
程式碼:https://github.com/ethz-asl/COIN-LIO(授權:BSD-3-Clause (LICENSE file checked))。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。