LVI-SAM
LVI-SAM 以因子圖(factor graph)為核心,將視覺慣性子系統(VIS)與光達慣性子系統(LIS)緊密耦合:LIS 提供位姿與 IMU 偏差協助 VIS 初始化,VIS 的視覺里程計則作為光達掃描配準(scan matching)的初始猜測。視覺特徵可由累積的光達點取得深度,迴圈(loop closure)候選先由 DBoW2 視覺詞袋產生,再以光達配準精修後加入 iSAM2 全域最佳化。任一子系統偵測到失效時可被繞過,以提升在無紋理或幾何退化場景的穩健性。
本頁內容
A factor-graph LiDAR-visual-inertial system in which a VINS-Mono-style visual-inertial subsystem and a LIO-SAM-style lidar-inertial subsystem exchange initial guesses and depth, with visual place recognition refined by LiDAR scan matching for loop closure.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | 3D LiDAR (Velodyne VLP-16)、IMU (MicroStrain 3DM-GX5-25)、monocular camera (FLIR BFS-U3-04S2M-CS)、GPS (Reach RS+, ground-truth reference only) |
|---|---|
| 原文測試平台 | handheld、wheeled UGV (Clearpath Jackal) |
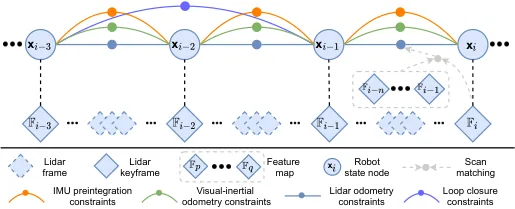
| 狀態估計 | factor graph smoothing with iSAM2 in the lidar-inertial subsystem (IMU preintegration, visual odometry, lidar odometry and loop factors); VINS-Mono-style sliding-window bundle adjustment in the visual-inertial subsystem |
| 資料關聯 | LiDAR edge and planar features matched scan-to-map against a sliding-window keyframe feature map (adapted from LIO-SAM); KLT-tracked corner features with depth from stacked LiDAR points (3 nearest points on a unit sphere, plane intersection, 2 m consistency check) |
| 時間表示 | discrete poses (keyframes); IMU-rate pose output |
| 去畸變 | LiDAR point clouds de-skewed with IMU measurements before feature extraction (Fig. 1, Sec. I) |
| 迴圈閉合 | DBoW2 with BRIEF descriptors proposes candidates in the VIS; candidates refined by LiDAR scan matching in the LIS (Sec. II-B4, II-C) |
| 全域最佳化 | incremental factor graph optimization (iSAM2) including loop closure factors |
| 地圖表示 | global LiDAR feature map built from keyframes; sparse visual landmarks in the VIS |
| 先驗資訊 | none |
| 可輸出幾何 | 原文未報告 (paper evaluates trajectories; no colored map or export format described) |
| 計算需求 | real-time claimed; all methods run on a laptop with Intel i7-10710U CPU (Sec. III); per-module timing not reported |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
| LiDAR | Velodyne VLP-16 | 方法輸入 | 未標示 | 原文未報告 | (Shan et al., 2021, Sec. III) |
| 慣性量測單元(IMU) | MicroStrain 3DM-GX5-25 | 方法輸入 | 未標示 | 原文未報告 | (Shan et al., 2021, Sec. III) |
| GNSS 接收器 | Reach RS+ GPS | 參考或真值量測 | 未標示 | used as ground truth where reception is available | (Shan et al., 2021, Sec. III; Fig. 8) |
| 相機 | FLIR BFS-U3-04S2M-CS | 方法輸入 | 未標示 | 原文未報告 | (Shan et al., 2021, Sec. III) |
| 載具平台 | Clearpath Jackal unmanned ground vehicle | 方法輸入 | Jackal | manually driven | (Shan et al., 2021, Sec. III-B) |
| 載具平台 | handheld sensor suite carried by an operator | 方法輸入 | Urban; Handheld | 原文未報告 | (Shan et al., 2021, Sec. III-A; Sec. III-C) |
| 運算硬體 | laptop with Intel i7-10710U (Ubuntu Linux) | 執行運算平台 | 未標示 | all compared methods executed on it | (Shan et al., 2021, Sec. III) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
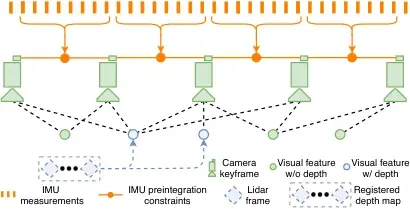
Fig. 2視覺慣性子系統框架:IMU 預積分、無深度與有深度的視覺量測共同最佳化
出處:Shan et al., 2021,Fig. 2。授權:CC0 1.0 public domain dedication (arXiv v2 per abs page); version of record (c) 2021 IEEE。原始圖檔。修改:轉存為 WebP 格式。
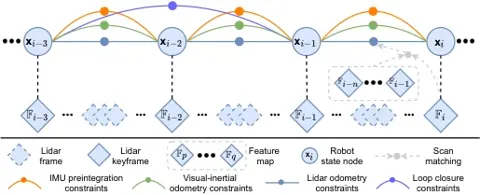
Fig. 5光達慣性子系統的因子圖:IMU 預積分、視覺里程計、光達里程計與迴圈約束
出處:Shan et al., 2021,Fig. 5。授權:CC0 1.0 public domain dedication (arXiv v2 per abs page); version of record (c) 2021 IEEE。原始圖檔。修改:轉存為 WebP 格式。
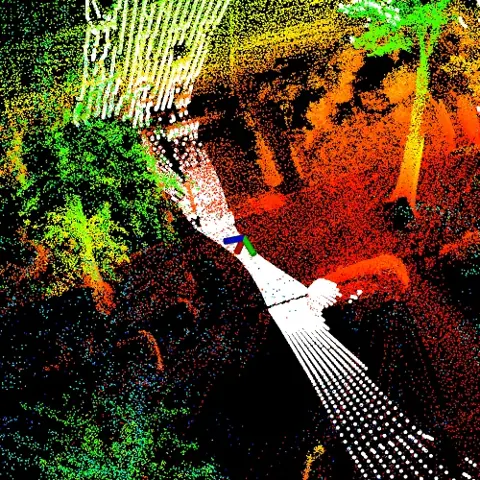
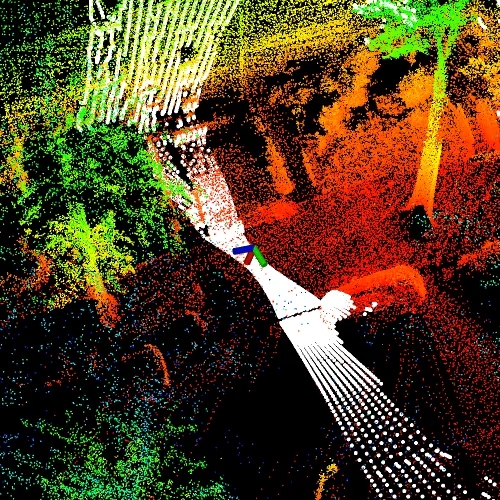
Fig. 6掃描配準退化情境:光達朝向地面,以及平坦開闊無結構的場地;連結影像僅為子圖 (c),即光達朝向地面時的掃描點雲
出處:Shan et al., 2021,Fig. 6。授權:CC0 1.0 public domain dedication (arXiv v2 per abs page); version of record (c) 2021 IEEE。原始圖檔。修改:轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Either subsystem can be bypassed on detected failure, keeping the system running in texture-less or feature-less scenes (abstract; Sec. II-B3, II-C2)
- LiDAR-derived feature depth reduced end-to-end drift in the ablation (Table I, Urban dataset)
- Completed the Handheld dataset (open baseball field) with or without loop closure; the authors state all lidar-based methods failed to generate meaningful results there (LOAM, LIO-mapping, LINS and LIO-SAM with loop marked Fail; LIO-SAM without loop reported 53.62 m RMSE), and LVI-SAM had the lowest errors in Table II (Sec. III-C)
限制
- VIS fails under aggressive motion, illumination change and texture-less scenes and must be detected and re-initialized (Sec. II-B3)
- LIS scan matching is ill-constrained when the LiDAR faces the ground or open flat areas (Sec. II-C2, Fig. 6)
- On the Jackal dataset LINS with loop closure has a lower end-to-end translation error (0.09 m) than LVI-SAM with loop closure (0.11 m) (Table II, Sec. III-B)
- Follow-up work reports LVI-SAM failing on nine of 25 NTU-VIRAL/Hilti sequences with loop closure disabled, attributed to feature-based subsystems (Zheng et al., 2025, Sec. IX-B)
- No map-geometry accuracy evaluation; reference is GPS trajectory only (inference from Sec. III)
營建工程相關證據
原論文未於營建工地、隧道或既有建物做驗證;三組自採資料為戶外都市街區(Urban,手持,含建物、車輛、行人與植被,植被遮蔽使 GPS 失效)、Jackal 無人地面車行經的結構物、植被與多種路面區域,以及含開闊棒球場的草地(Handheld);論文未稱其為校園。後續 FAST-LIVO2 論文在含工地序列的 Hilti 資料集上將其(關閉迴圈)作為比較基準,並報告多個序列失敗(Zheng et al., 2025, Sec. IX-B)。
原文驗證環境:獨立參考量測
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 20 個比較組,合計 196 筆紀錄。以下列出本方法紀錄最多的 4 組,其餘 16 組列在最後,並連到性能比較頁。
Lin & Zhang, 2024 · Table III 本方法 26 筆
表格設定(擷取紀錄原文):VoR Table III: absolute position error (APE, m) with standard deviation on NCLT (front-facing camera and 3D LiDAR, Segway robot), computed on the odometry output at LiDAR input for every method; loop closure of LIO-SAM and LVI-SAM deactivated; photometric calibration disabled for R3LIVE++ (unavailable for NCLT); '-' = failed midway, excluded from the averages; Our_LIO column omitted. The text says 2012-03-17 and 2012-08-04 were excluded for a 100 ms LiDAR-IMU timestamp delay, yet both appear in the 25-row table. (Lin & Zhang, 2024, Table III)
APE (m),NCLT · 2012-01-08 (6495.7 m, 01:25:35)
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Lin & Zhang, 2024 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Lin & Zhang, 2024, Table III)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| Our (R3LIVE++)原文提出 | 10.8 m原文指標寫法:APE (m), printed with STD 2.7 m | (Lin & Zhang, 2024, VoR Table III) |
| R2LIVE | 22.4 m原文指標寫法:APE (m), printed with STD 3.5 m | (Lin & Zhang, 2024, VoR Table III) |
| LVI-SAM本方法 | 23.4 m原文指標寫法:APE (m), printed with STD 3.7 m | (Lin & Zhang, 2024, VoR Table III) |
| FAST-LIVO | 13.4 m原文指標寫法:APE (m), printed with STD 2.9 m | (Lin & Zhang, 2024, VoR Table III) |
| Fast-LIO2 | 18.5 m原文指標寫法:APE (m), printed with STD 3.3 m | (Lin & Zhang, 2024, VoR Table III) |
| LIO-SAM | 21.7 m原文指標寫法:APE (m), printed with STD 3.6 m | (Lin & Zhang, 2024, VoR Table III) |
Lin & Zhang, 2022 · Table III 本方法 24 筆
表格設定(擷取紀錄原文):Relative rotation error (RRE, deg) and relative translation error (RTE, %) over all sub-sequences of 50 to 300 m in two seaport sequences (Belcher Bay Promenade) with D-GPS RTK ground truth; R3LIVE-HiRes uses 1280x1024 images and 0.01 m map point spacing, R3LIVE-RT 320x256 images and 0.10 m; LVI-SAM run with a modified LiDAR front-end for the Livox Avia; identical values in arXiv v1 and the version of record (Lin & Zhang, 2022, Table III)
RRE (deg) over 50 m sub-sequences,R3LIVE Experiment-3 (authors' data, D-GPS RTK) · Experiment-3 (a), 50 m sub-sequences
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Lin & Zhang, 2022 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Lin & Zhang, 2022, Table III)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| R3LIVE-HiRes原文提出 | 0.99 deg | (Lin & Zhang, 2022, VoR Table III) |
| R3LIVE-RT原文提出 | 1.48 deg | (Lin & Zhang, 2022, VoR Table III) |
| LVI SAM本方法 | 2.11 deg | (Lin & Zhang, 2022, VoR Table III) |
| R2LIVE | 1.21 deg | (Lin & Zhang, 2022, VoR Table III) |
| FAST-LIO2 | 1.36 deg | (Lin & Zhang, 2022, VoR Table III) |
| VINS-Mono | 3.03 deg | (Lin & Zhang, 2022, VoR Table III) |
Zheng et al., 2025 · Table II 本方法 17 筆
資料集與序列NTU-VIRAL, Hilti'22, Hilti'23 · Average (25 sequences)
表格設定(擷取紀錄原文):Absolute translational error RMSE on Hilti'22 and Hilti'23 (handheld: PandarXT-32, BMI085; robot: BPearl, MTi-670; front camera), scored through the official Hilti website because ground truth (MoCap or total station) is not public; loop closure of LVI-SAM removed; ablation columns kept only in the Average row; NTU-VIRAL rows omitted for the row cap; Average over all 25 sequences (NTU-VIRAL, Hilti'22, Hilti'23; how failed runs enter the average is not stated) (Zheng et al., 2025, Table II)
absolute translational errors (RMSE), Average row,NTU-VIRAL, Hilti'22, Hilti'23 · Average (25 sequences)
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Zheng et al., 2025 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Zheng et al., 2025, Table II)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| SDV-LOAM | 7.416 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| Our LIO | 0.097 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| FAST-LIO2 | 0.151 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| R3LIVE | 0.278 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| LVI-SAM本方法 | 1.928 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| FAST-LIVO | 0.137 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| Ours原文提出 | 0.045 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| Ours (w/o expo) | 0.051 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| Ours (w normal) | 0.044 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
| Ours (w/o update) | 0.089 m | (Zheng et al., 2025, Table II (Average row); text Sec. IX-B states 0.044 m for Ours) |
Zhou et al., 2025 · Table I 本方法 17 筆
表格設定(擷取紀錄原文):ATE RMSE on 16 Hilti'22 and Hilti'23 sequences computed with the official Hilti evaluation tools; parameters of all methods tuned by the authors; x = system totally failed (Zhou et al., 2025, Table I)
ATE (RMSE),Hilti'22 · Construction Ground
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 失敗
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Zhou et al., 2025 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Zhou et al., 2025, Table I)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| Ours原文提出 | 0.01 m | (Zhou et al., 2025, Table I) |
| FAST-LIVO2 | 0.01 m | (Zhou et al., 2025, Table I) |
| FAST-LIO2 | 0.013 m | (Zhou et al., 2025, Table I) |
| FAST-LIVO | 0.022 m | (Zhou et al., 2025, Table I) |
| R3LIVE | 0.021 m | (Zhou et al., 2025, Table I) |
| SDV-LOAM | 25.121 m | (Zhou et al., 2025, Table I) |
| LVI-SAM本方法 | 無數值失敗註記(擷取紀錄):failed (x) | (Zhou et al., 2025, Table I) |
其他比較組
列出其餘 16 個比較組
- Chen et al., 2025b · Table 5
- Xie et al., 2025 · Supp. Table 7
- Shan et al., 2021 · Table I
- Shan et al., 2021 · Table II
- Hong et al., 2025 · Table II
- Cramariuc et al., 2023 · Table II
- Yan et al., 2026a · Table 1
- Yan et al., 2026a · Table 5
- Lv et al., 2023 · Table VII
- Lv et al., 2023 · Table V
- Zheng et al., 2025 · Table III
- Lang et al., 2023 · Table IV
- Ghadimzadeh Alamdari et al., 2025 · Table 3
- Ghadimzadeh Alamdari et al., 2025 · Text Sec.7.1.2
- Yan et al., 2026a · Table 3
- Yan et al., 2026a · Text Sec. 4.3
來源
Shan et al., 2021
(2021)LVI-SAM: Tightly-coupled Lidar-Visual-Inertial Odometry via Smoothing and Mapping2021 IEEE International Conference on Robotics and Automation (ICRA), pp. 5692-5698
DOI 10.1109/icra48506.2021.9561996arXiv 2104.10831程式碼
同儕審查已出版已讀全文近十年查證後修正
相關版本
- 預印本:LVI-SAM (arXiv v1 2021-04-22, v2 2021-05-30) https://arxiv.org/abs/2104.10831
- 程式碼釋出:TixiaoShan/LVI-SAM https://github.com/TixiaoShan/LVI-SAM
程式碼:https://github.com/TixiaoShan/LVI-SAM(授權:BSD-3-Clause (LICENSE file checked))。有公開程式碼不等於已被重現,也不代表目前版本與論文版本相同。