Super Odometry
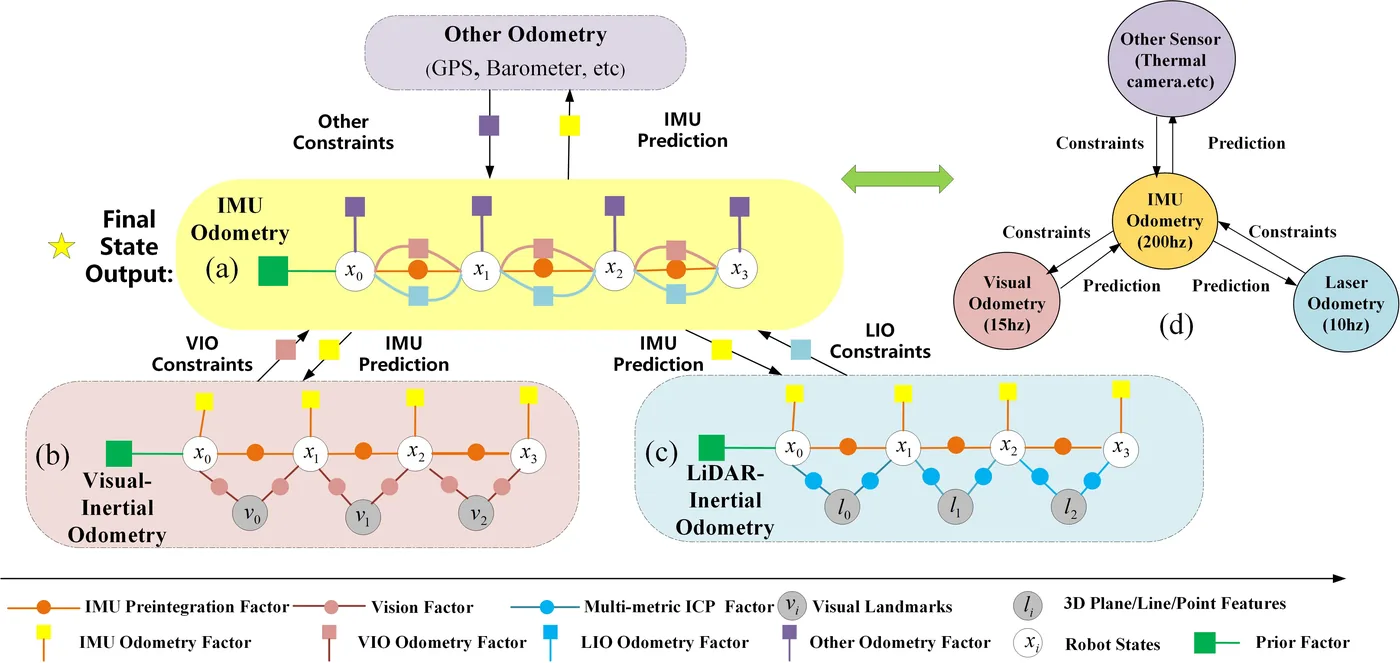
Super Odometry 以 IMU 為中心:IMU 里程計提供運動預測給視覺慣性與光達慣性子系統,後兩者回傳相對位姿約束來限制 IMU 偏差,形成由粗到細的估計流程,兼具鬆耦合的容錯與緊耦合的精度。光達端以 PCA 將點分類為點、線、面特徵並做多度量 ICP,地圖以動態八元樹(dynamic octree)組織以降低重建樹的成本。系統部署於 DARPA 地下挑戰賽的無人機與地面機器人。
本頁內容
An IMU-centric factor-graph design in which IMU odometry predicts motion for VIO and LIO and is constrained by their pose outputs, deployed in DARPA SubT underground environments.
技術屬性
欄位內容為文獻擷取紀錄的原文用語(英文),以原文為據;「未查證」表示本研究尚未讀到該資訊,不代表該方法不具備此能力。
| 感測輸入 | 3D LiDAR (Velodyne VLP-16)、IMU (Xsens)、fisheye monocular camera |
|---|---|
| 原文測試平台 | UAV、handheld、ground robot (type 未查證) |
| 狀態估計 | IMU-centric factor graph split into sub-graphs: IMU odometry (IMU preintegration plus relative-pose factors from VIO and LIO, weighted by covariances reflecting their reliability, with a marginalization prior) constrains the IMU biases; LIO solves scan-to-map registration by Levenberg-Marquardt with the IMU-odometry prior, and keyframe VIO minimizes reprojection, IMU and prior terms; estimates use historical frames in a sliding window and proceed coarse-to-fine (Secs. II-A, IV-A to IV-C) |
| 資料關聯 | PCA-based point, line and plane feature classification (linearity, planarity, curvature) with multi-metric point-to-point, point-to-line and point-to-plane ICP against the map through the dynamic octree; each correspondence weighted by how well its neighbours fit the assumed distribution, so noisy returns in dust are down-weighted or rejected (Sec. IV-B, Eqs. 5 to 8); monocular visual features tracked, with LiDAR points in the camera view providing feature depth (Sec. IV-C) |
| 時間表示 | discrete poses; submodules run asynchronously in parallel, each caching constraints and processing them in small batches at its own rate; IMU odometry can output state estimates at 1000 Hz (Sec. V-C2) |
| 去畸變 | 原文未報告 (full text read; no LiDAR motion-compensation step is described) |
| 迴圈閉合 | not used in reported experiments (Sec. V-B) |
| 全域最佳化 | none in reported experiments |
| 地圖表示 | dynamic octree: hash table of voxels each holding its own octree |
| 先驗資訊 | none |
| 可輸出幾何 | point cloud maps shown qualitatively (Fig. 6, Fig. 7); export 原文未報告 |
| 計算需求 | onboard Intel NUC on the DS drone (Sec. V-A); runtime benchmarked on an 8-core Intel Core i7-4790K desktop: LIO 13 to 21 ms versus LIO-SAM 23 to 102 ms, IMU odometry 0.8 to 0.9 ms, VIO 28 ms on Long Corridor and bypassed on the other runs (Table III); dynamic octree about 10% of the runtime of a static KD-tree (abstract; Fig. 8, plot only) |
使用設備
原文使用的感測器、運算硬體與載具(equipment)。型號保留原文寫法,連結到設備頁中同一型號的歸併名稱;角色依原文用途分為方法輸入、資料集感測器、執行運算平台、參考或真值量測(reference or ground truth)與比較對象設備。
| 類別 | 型號(原文寫法) | 角色 | 資料集 | 原文規格 | 出處 |
|---|---|---|---|---|---|
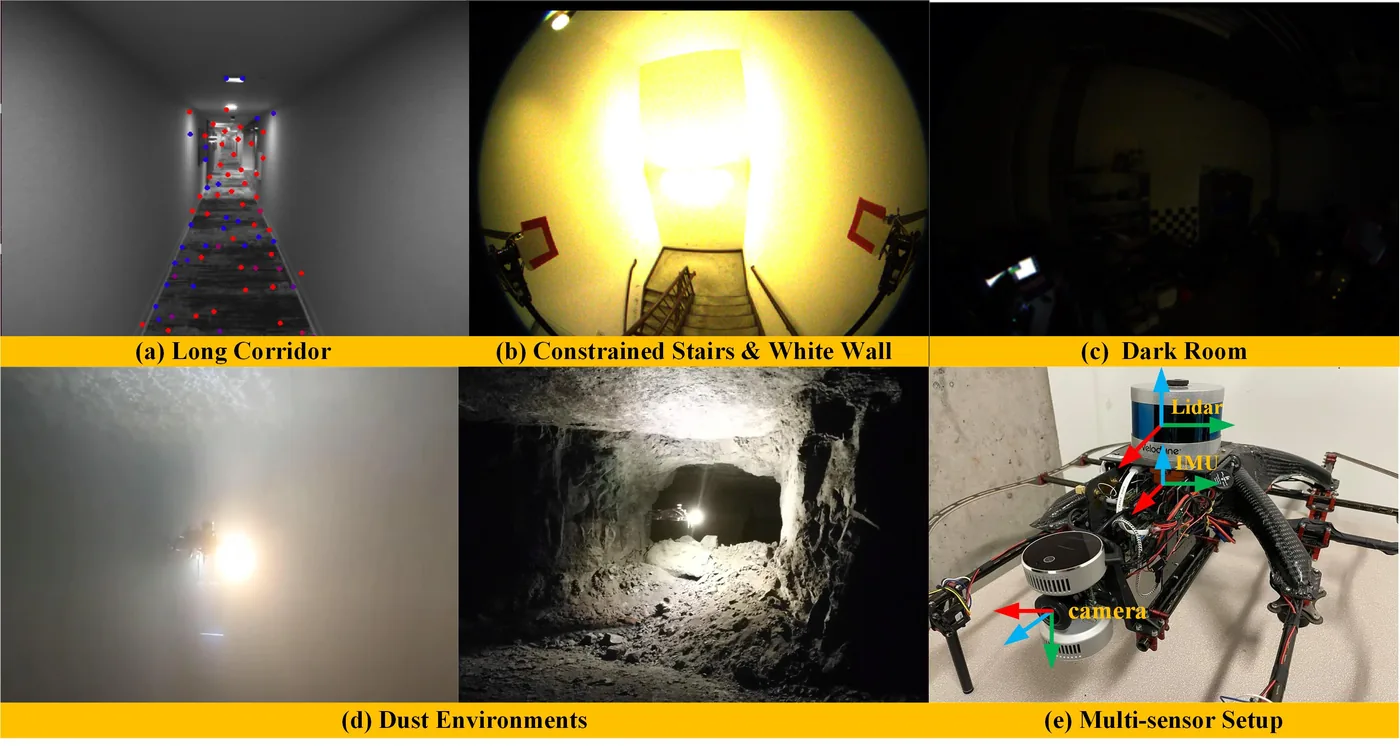
| LiDAR | Velodyne VLP-16 | 方法輸入 | 未標示 | 原文未報告 | (Zhao et al., 2021, Sec. V-A, Fig. 4(e)) |
| 慣性量測單元(IMU) | Xsens IMU (model 原文未報告)歸入:Xsens IMU (model not reported) | 方法輸入 | 未標示 | 原文未報告 | (Zhao et al., 2021, Sec. V-A) |
| 相機 | uEye camera with a wide-angle fisheye lens | 方法輸入 | 未標示 | monocular | (Zhao et al., 2021, Sec. V-A) |
| 全測站 | Total Station (TS) with a tracking prism on top of the sensor suite (model 原文未報告) | 參考或真值量測 | 未標示 | trajectory ground truth for Dark-Room, Long-Corridor, White-Wall and Constrained-Environment | (Zhao et al., 2021, Sec. V-A) |
| 載具平台 | DS drone (Team Explorer) | 方法輸入 | 未標示 | deployed in the DARPA Subterranean Challenge; hand-carried for four sequences, autonomous flight in Dust | (Zhao et al., 2021, Sec. V-A, Fig. 4(e)) |
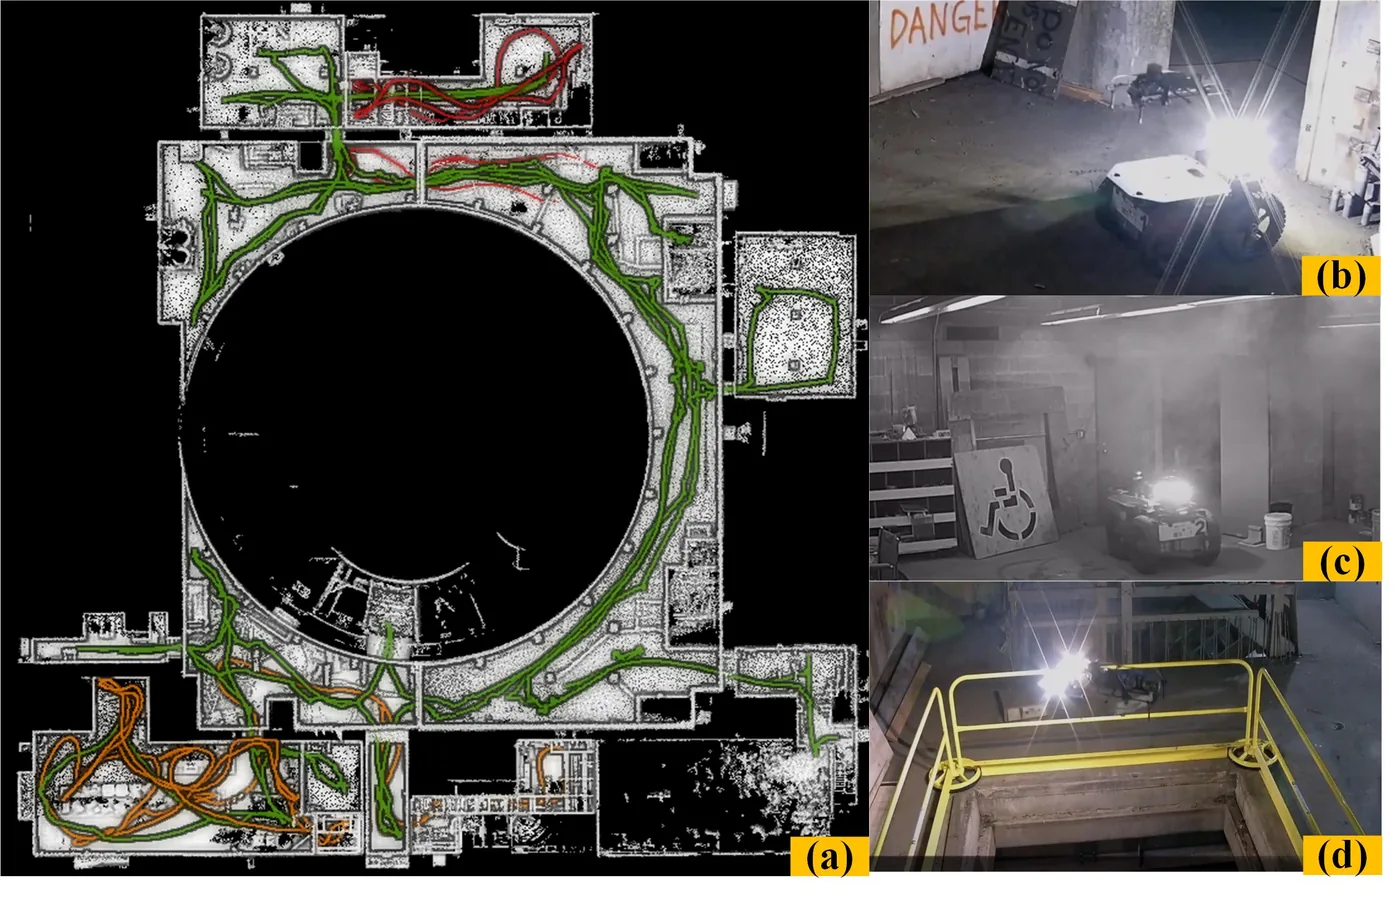
| 載具平台 | UGV1, UAV1 and UAV2 (Team Explorer robots) | 方法輸入 | 未標示 | multi-robot mapping in the DARPA SubT Urban Alpha Course | (Zhao et al., 2021, Fig. 1) |
| 運算硬體 | Intel NUC | 執行運算平台 | 未標示 | onboard computer of the DS drone sensor suite; no runtime numbers reported on it | (Zhao et al., 2021, Sec. V-A) |
| 運算硬體 | Intel Core i7-4790K | 執行運算平台 | 未標示 | 8-core CPU in a desktop PC used for all runtime benchmarks | (Zhao et al., 2021, Sec. V-C, Table III) |
論文圖片
只收錄原文以開放授權(open license)釋出的圖片,並依授權條件標示出處、圖號、授權與修改方式。
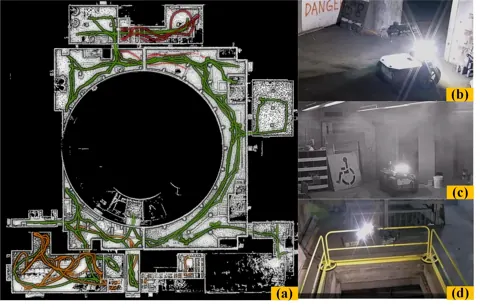
Fig. 1DARPA SubT Alpha Course 由 UGV1、UAV1、UAV2 多機器人建出的地圖,以及黑暗、濃霧、垂直豎井等情境
出處:Zhao et al., 2021,Fig. 1。授權:CC BY-NC-SA 4.0 (arXiv v2)。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
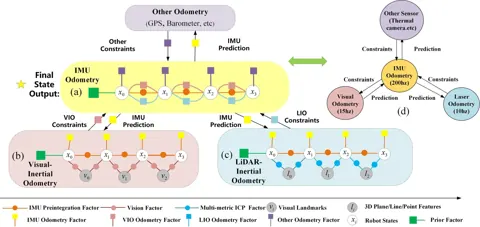
Fig. 2以 IMU 為中心的系統架構:IMU 里程計與 VIO、LIO 子因子圖互相提供預測與約束
出處:Zhao et al., 2021,Fig. 2。授權:CC BY-NC-SA 4.0 (arXiv v2)。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
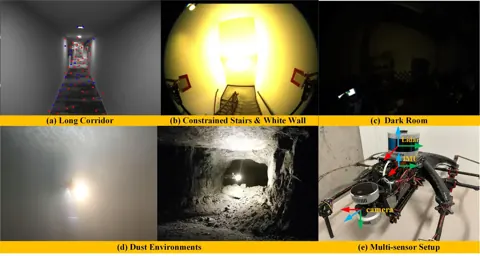
Fig. 4資料蒐集的困難環境(長走廊、白牆與樓梯井、暗室、粉塵洞穴)與無人機上的多感測器配置
出處:Zhao et al., 2021,Fig. 4。授權:CC BY-NC-SA 4.0 (arXiv v2)。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
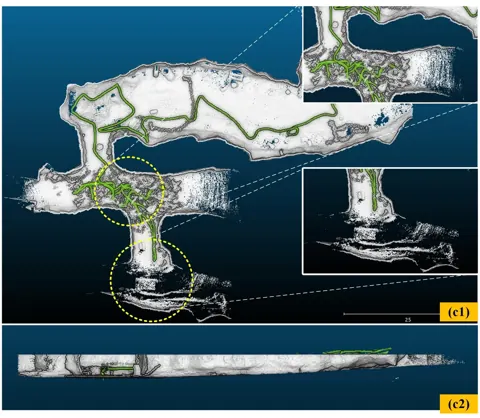
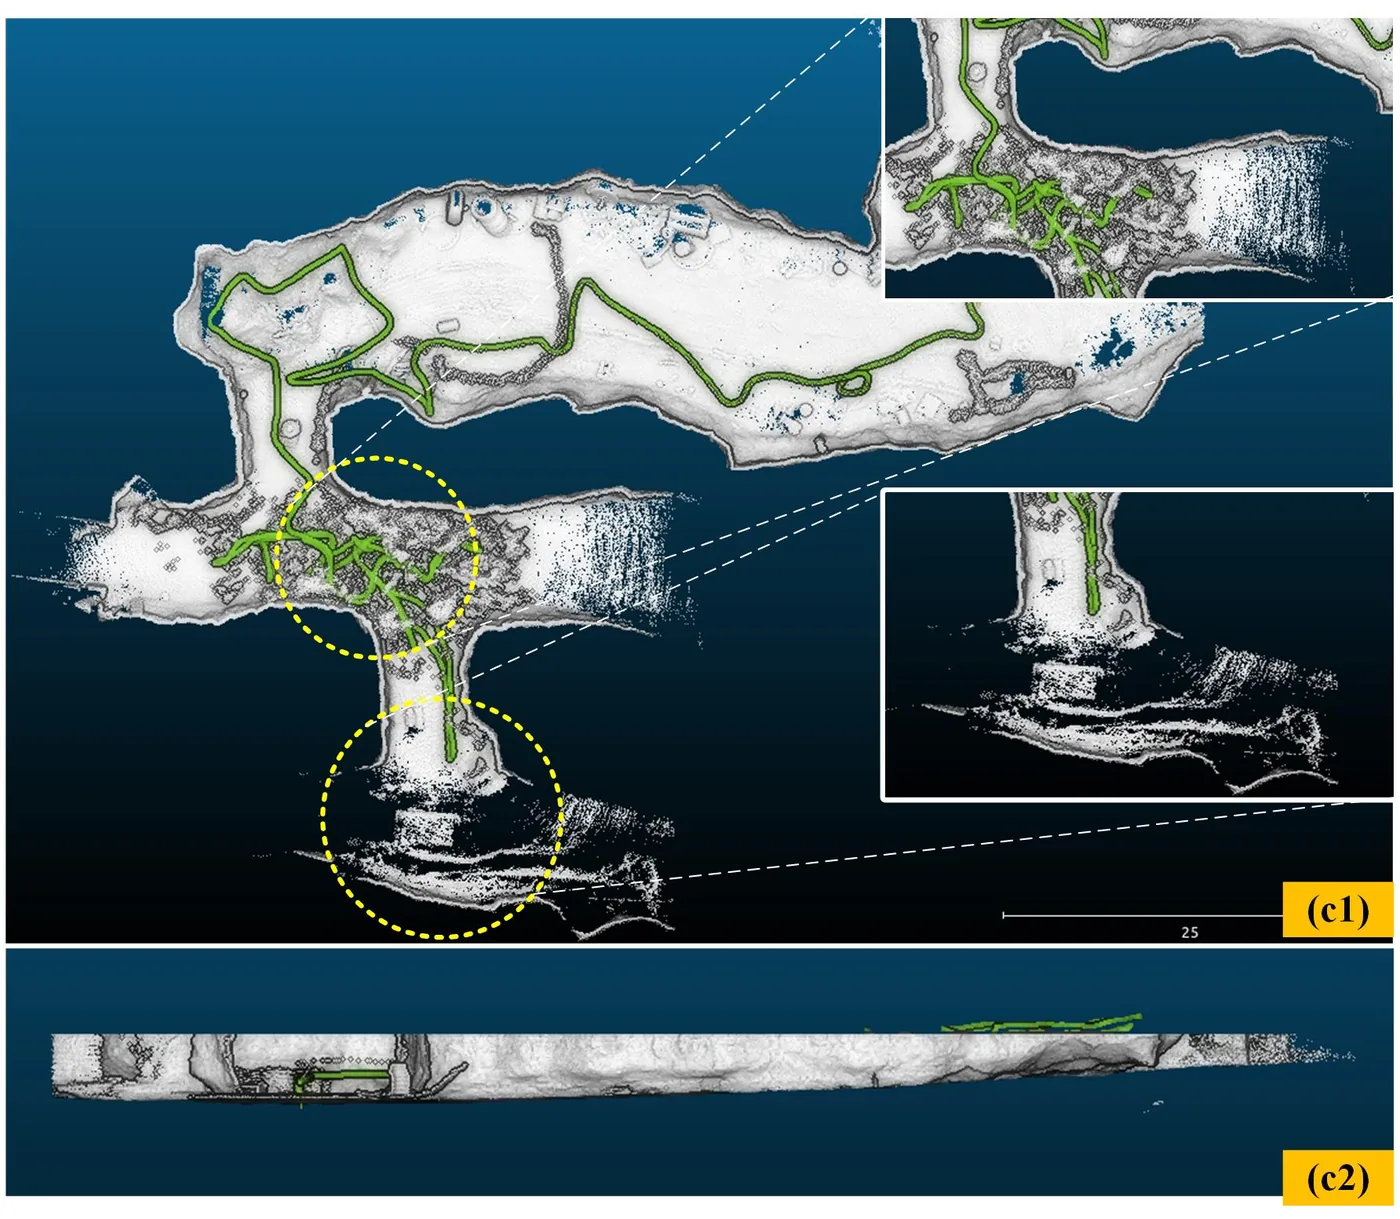
Fig. 7(c)粉塵序列中 Super Odometry 的地圖俯視圖與 z 向漂移圖(僅子圖 c)
出處:Zhao et al., 2021,Fig. 7(c)。授權:CC BY-NC-SA 4.0 (arXiv v2)。原始圖檔。修改:縮小至寬度不超過 1400 px,並轉存為 WebP 格式。
作者報告的優勢與限制
優勢
- Lowest RMSE ATE among compared methods on every total-station-referenced sequence; the 0.055 m value is for the Long-Corridor sequence (apartment building), with 0.259, 0.156 and 0.174 m on Constrained-Environment, White-Wall and Dark-Room (Sec. V-B, Table II)
- Remained operational in dust, dark-room, long-corridor and stair-shaft sequences where some baselines degraded: both vision-only methods failed in the Dust sequence and LOAM showed map misalignment; LiDAR baselines did not fail outright on the total-station sequences (Sec. V-B, Figs. 6-7, Table II)
限制
- Loop closing not used in experiments; odometry-only evaluation (Sec. V-B)
- Dust sequence and Urban Circuit run lack trajectory ground truth (Sec. V-A)
- Map quality is compared only qualitatively (top-down and z-drift views, Figs. 6 to 7); no quantitative map metric is reported
- (inference) Quantitative accuracy rests on four short hand-carried sequences collected by the authors; no public benchmark is used (Sec. V-A, Table II)
營建工程相關證據
作者資料含公寓大樓長走廊、樓梯井(受限環境)、暗室與白牆等手持序列,這些序列以全測站(Total Station)追蹤稜鏡提供參考軌跡;粉塵洞穴與 DARPA SubT Urban(廢棄核設施)序列則無軌跡真值,只做定性地圖比較與效能分析。屬既有建物與地下情境,非營建工地。
原文驗證環境:地下或隧道、已完工建築、獨立參考量測
報告的性能數據
以下是原文作者報告的性能數值(author-reported results),不是本研究重新量測的結果。每張圖只並列同一個比較組(comparison group,同一張表、同一組實驗設定)內的方法;不同比較組之間的數值不可直接比較,也不構成排名。
本方法共出現在 3 個比較組,合計 25 筆紀錄。
Zhao et al., 2021 · Table III 本方法 16 筆
指標average running time (ms)
表格設定(擷取紀錄原文):Average running time per module; submodules run in parallel so total time equals the slowest submodule; 'bypass' = VIO not run (Zhao et al., 2021, Table III)
average running time (ms),authors' DS-drone data · Dust
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 未執行
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Zhao et al., 2021 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Zhao et al., 2021, Table III)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| Super Odometry LIO submodule本方法原文提出硬體:desktop PC, 8-core Intel Core i7-4790K | 21 ms | (Zhao et al., 2021, Table III) |
| Super Odometry VIO submodule本方法原文提出硬體:desktop PC, 8-core Intel Core i7-4790K | 無數值未執行註記(擷取紀錄):bypass (as printed in Table III; VIO submodule bypassed in this run) | (Zhao et al., 2021, Table III) |
| Super Odometry IMU odometry submodule本方法原文提出硬體:desktop PC, 8-core Intel Core i7-4790K | 0.8 ms | (Zhao et al., 2021, Table III) |
| Ours (Super Odometry, total = slowest parallel submodule)本方法原文提出硬體:desktop PC, 8-core Intel Core i7-4790K | 21 ms | (Zhao et al., 2021, Table III) |
| LIO-SAM硬體:desktop PC, 8-core Intel Core i7-4790K | 102 ms | (Zhao et al., 2021, Table III) |
Zhao et al., 2021 · Table II 本方法 8 筆
表格設定(擷取紀錄原文):Translational ATE computed with evo against total-station prism trajectory; odometry only, no loop closing (Zhao et al., 2021, Table II)
ATE (in m) Transl. MAX,authors' DS-drone sensor-suite data (hand-carried) · Constrained environments
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Zhao et al., 2021 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Zhao et al., 2021, Table II)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| LOAM | 0.779 m | (Zhao et al., 2021, Table II) |
| LIO-SAM | 1.914 m | (Zhao et al., 2021, Table II) |
| VINS (VINS-Mono) | 0.907 m | (Zhao et al., 2021, Table II) |
| VINS-Depth (authors' depth-enhanced VINS [20]) | 0.972 m | (Zhao et al., 2021, Table II) |
| Ours (Super Odometry)本方法原文提出 | 0.609 m | (Zhao et al., 2021, Table II) |
Ghadimzadeh Alamdari et al., 2025 · Table 3 本方法 1 筆
指標Result (run outcome)
資料集與序列Luleå SubT tunnel dataset (Koval et al. 2022)
表格設定(擷取紀錄原文):Run outcome ('Result' column) of each reviewed LiDAR-based and combined method on the Luleå tunnel test dataset; '*' marks incompatible with VLP-16, '+' marks not integrated with ROS; some rows combine two methods (Ghadimzadeh Alamdari et al., 2025, Table 3)
Result (run outcome),Luleå SubT tunnel dataset (Koval et al. 2022)
只並列這張表在相同設定下報告的方法;以「本方法:」開頭者為本頁方法。失敗、未執行與未報告以標記呈現,不是 0。
- 未執行
- 失敗
- 未報告(沒有數值,不是 0)
按 Tab 進入圖表後,用上下方向鍵逐一瀏覽各類別,Esc 關閉提示框;也可開啟表格檢視閱讀全部數值。
這些是 Ghadimzadeh Alamdari et al., 2025 在此表設定下報告的數值(author-reported results),只能在同一個比較組內對照,不代表方法在其他資料或設定下的表現。
資料來源作者報告值(Ghadimzadeh Alamdari et al., 2025, Table 3)
| 方法(原文寫法) | 報告值 | 出處 |
|---|---|---|
| LOAM and A-LOAM | 無數值未報告註記(擷取紀錄):success (row covers LOAM and A-LOAM; A-LOAM is the variant discussed in the results) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LOAM-Livox | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| F-LOAM | 無數值未報告註記(擷取紀錄):success | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LeGO-LOAM | 無數值未報告註記(擷取紀錄):success | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| ISC-LOAM | 無數值失敗註記(擷取紀錄):failed (trajectory estimation) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| SC-LeGO-LOAM | 無數值未報告註記(擷取紀錄):success | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| Optimized-SC-F-LOAM | 無數值未執行註記(擷取紀錄):未執行 (incompatible with the testing dataset) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| PIN-SLAM | 無數值未執行註記(擷取紀錄):未執行 (not integrated with ROS) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| M-LOAM | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| MULLS | 無數值失敗註記(擷取紀錄):failed (trajectory estimation) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LOL | 無數值失敗註記(擷取紀錄):failed (trajectory estimation) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| SegMap | 無數值未執行註記(擷取紀錄):未執行 (authors could not run the code) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| SuMa++ | 無數值未執行註記(擷取紀錄):未執行 (authors could not run the code) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| SuMa | 無數值未執行註記(擷取紀錄):未執行 (authors could not run the code) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| IMLS-SLAM | 無數值未執行註記(擷取紀錄):未執行 (no publicly available repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| HDL-Graph-SLAM | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LIOM | 無數值未執行註記(擷取紀錄):未執行 (inconsistent repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LIO-SAM | 無數值未報告註記(擷取紀錄):success | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LINS | 無數值未報告註記(擷取紀錄):success | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LiLi-OM | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| Fast-LIO 1 | 無數值未執行註記(擷取紀錄):未執行 (repository no longer available) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| Fast-LIO 2 and SC-Fast-LIO 2 | 無數值未報告註記(擷取紀錄):success (row covers Fast-LIO 2 and its Scan Context variant) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| D-LIOM | 無數值未執行註記(擷取紀錄):未執行 (inconsistent repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| Hand-held mobile mapping | 無數值未執行註記(擷取紀錄):未執行 (not integrated with ROS) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| HectorGrapher | 無數值未執行註記(擷取紀錄):未執行 (inconsistent repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| Cartographer | 無數值未執行註記(擷取紀錄):未執行 (authors could not run the code) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LOCUS and LOCUS 2 | 無數值未執行註記(擷取紀錄):未執行 (authors could not run the code) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| CamVox | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LVI-SAM | 無數值未報告註記(擷取紀錄):success | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| R2LIVE | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| R3LIVE | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| FAST-LIVO(s) | 無數值未執行註記(擷取紀錄):未執行 (incompatible with VLP-16) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| LIMO | 無數值未執行註記(擷取紀錄):未執行 (authors could not run the code) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| DV-LOAM | 無數值未執行註記(擷取紀錄):未執行 (inconsistent repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| DVL-SLAM | 無數值未執行註記(擷取紀錄):未執行 (inconsistent repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| Multiverse Odometry | 無數值未執行註記(擷取紀錄):未執行 (inconsistent repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
| Super Odometry本方法 | 無數值未執行註記(擷取紀錄):未執行 (no publicly available repository) | (Ghadimzadeh Alamdari et al., 2025, Table 3) |
來源
Zhao et al., 2021
(2021)Super Odometry: IMU-centric LiDAR-Visual-Inertial Estimator for Challenging Environments2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 8729-8736
DOI 10.1109/iros51168.2021.9635862arXiv 2104.14938
同儕審查已出版已讀全文近十年查證後修正
相關版本
- 預印本:Super Odometry arXiv (v1 2021-04-30, v2 2021-08-20) https://arxiv.org/abs/2104.14938